Mobile Manipulation
Background
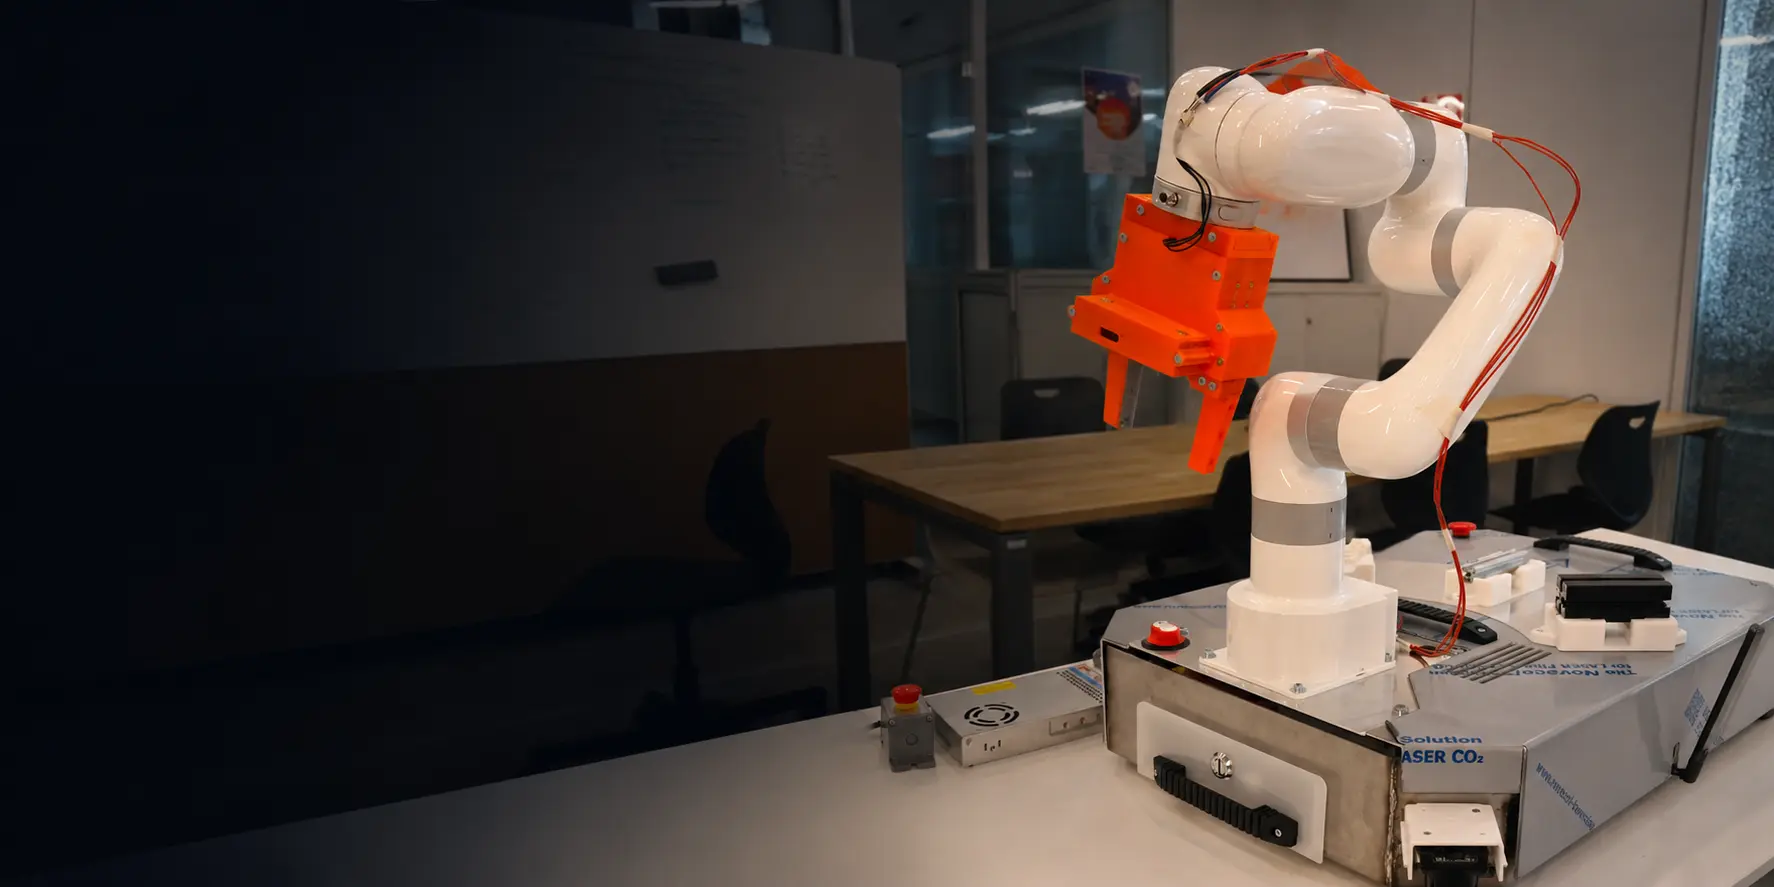
Combining a mobile platform with a collaborative robot is a key capability for logistics, flexible manufacturing, and service robotics. University competitions, such as RoboCup@Work, and research teams are also among the main developers in this field.
However, mounting a collaborative robot on a mobile platform comes with strict limits on space, weight, and power supply. A robotic arm that still requires an external control box is often difficult to integrate. This is the first major challenge in mobile manipulation integration.
Industry Pain Points

Size, Cost, and Closed Systems
Robotic arms that require an external control box take up more space and add weight, making compact integration on a mobile base difficult.
Students and research teams with limited budgets often struggle to afford expensive collaborative robots.
Integrating navigation and manipulation requires open interfaces. Closed systems make it difficult to connect the full workflow of navigation, perception, and grasping.
 01
Budget-Friendly
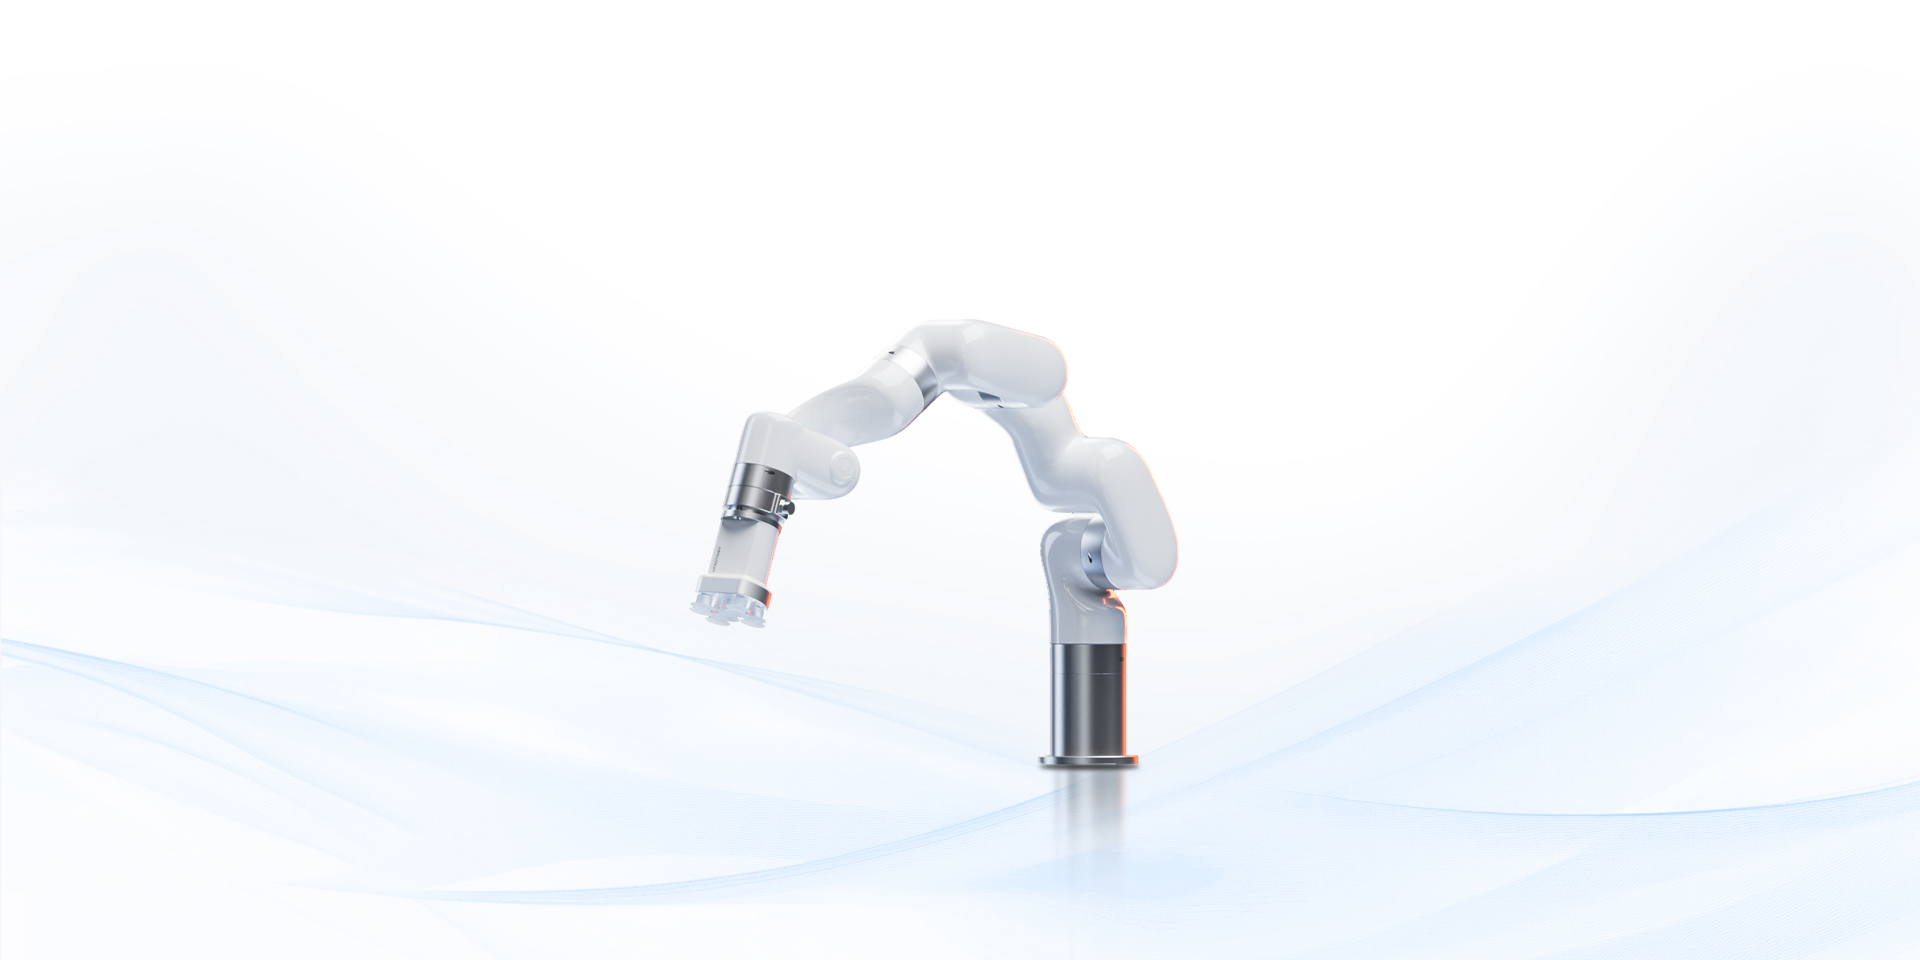
Lite 6 lowers the entry barrier for mobile manipulation research, education, and competitions while maintaining reliable collaborative robot performance.
 02
All-in-One Design
Lite 6 integrates the controller inside the arm, reducing system footprint, weight, and wiring for compact mobile bases with limited payload.
 03
Seamless Integration with Mobile Platforms
Standard Ethernet connectivity links the arm with onboard computers such as NVIDIA Jetson, enabling coordinated navigation, perception, localization, and manipulation.
 04
Open Development Ecosystem
ROS/ROS2 packages and Python/C++ SDKs support custom workflows from positioning and perception to grasping, placement, and high-level task planning.
 05
Vision Integration
Compatible with 3D depth cameras, Lite 6 supports object detection, pose estimation, 3D localization, and reliable autonomous grasp adjustments.
 06
Reliable and Durable
Stable hardware supports repeated testing, competitions, research projects, and continuous mobile manipulation development.
 07
More Robot Options
For higher payload and reach, xArm 6 offers a 12.5 kg arm and compact 2.5 kg DC control box for AGVs and AMRs.
Related Case Studies
Mobile Manipulation
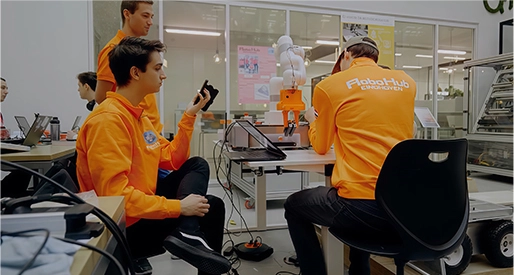
RoboHub Eindhoven
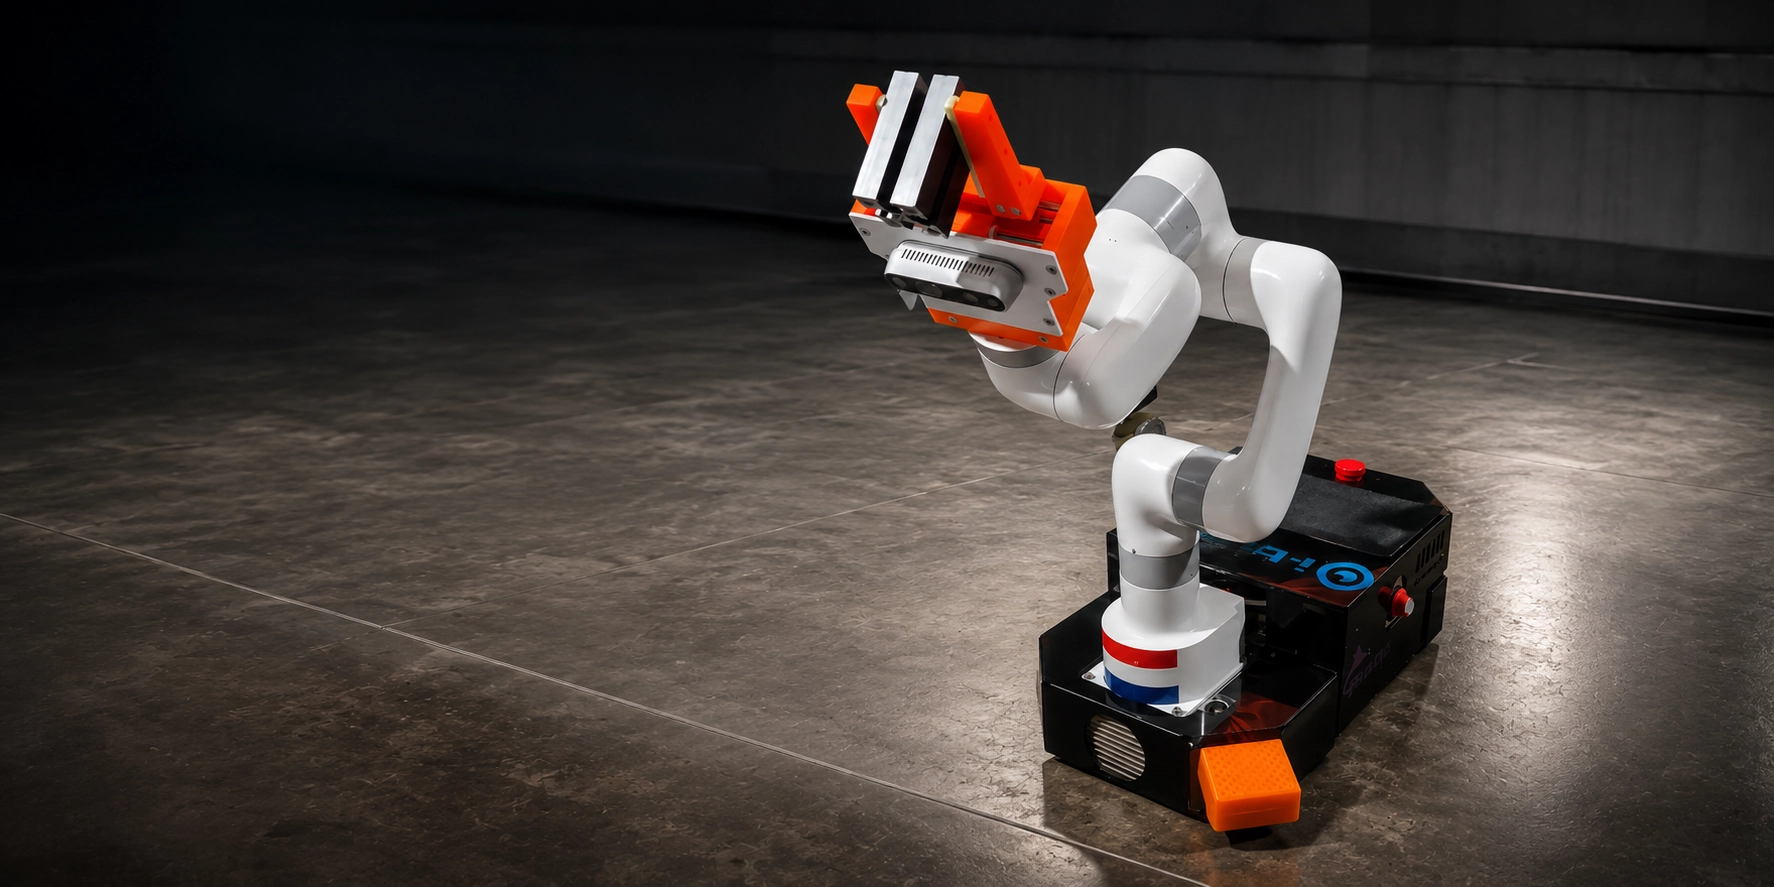
RoboHub Eindhoven integrated the UFACTORY Lite 6 onto AMRs for RoboCup@Work, leveraging its built-in control box, open-source SDKs, and outstanding price-performance ratio to achieve autonomous Industry 4.0 precision handling.
VR Teleoperation & Autonomous Bin Picking
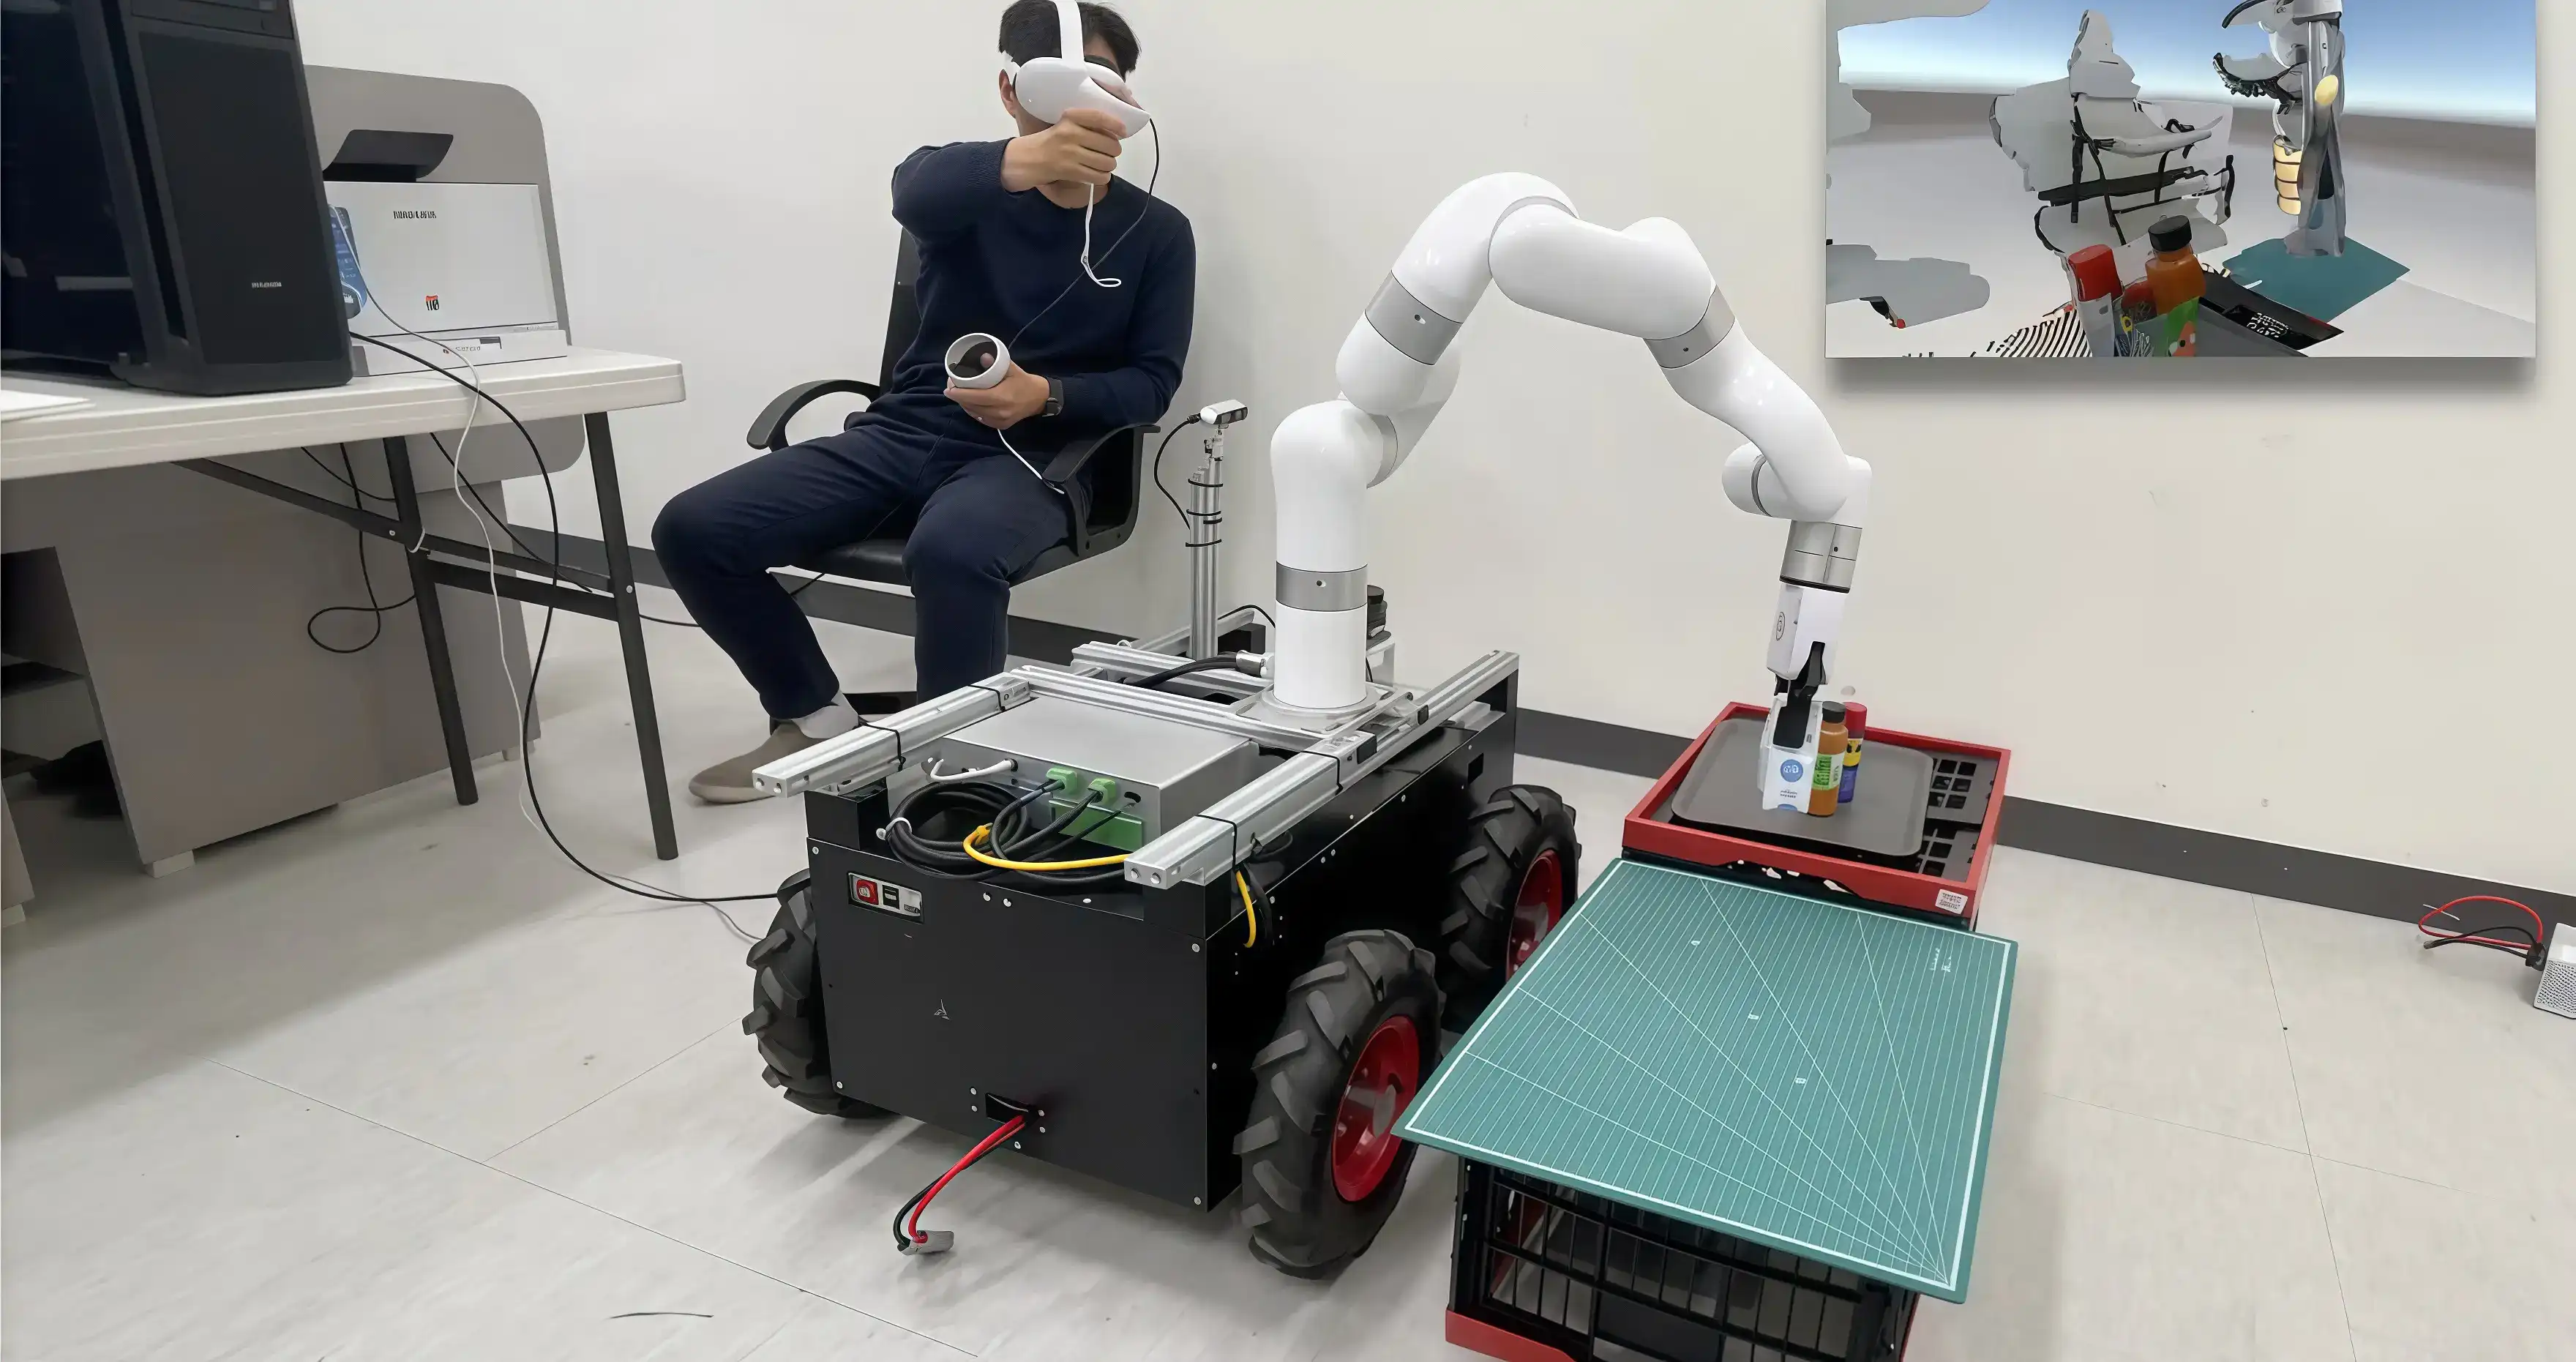
AMR Labs
AMR Labs developed VR teleoperation and autonomous bin picking applications with UFACTORY xArm.
Not sure which model fits your workflow?
Our team will match the right robot and configuration to your needs.