VR Teleoperation & Autonomous Bin Picking
ARM LAbs Inc.
In Short
Founded in 2020 and based in Hwaseong, Gyeonggi-do, AMR Labs Inc. is a South Korean robotics company specializing in autonomous mobile robot (AMR) solutions for logistics, factory integration, and mobile manipulation. The company develops complete mobile manipulator systems—combining AMR platforms with robot arms to deliver flexible automation that can both navigate autonomously and interact with objects in the environment.
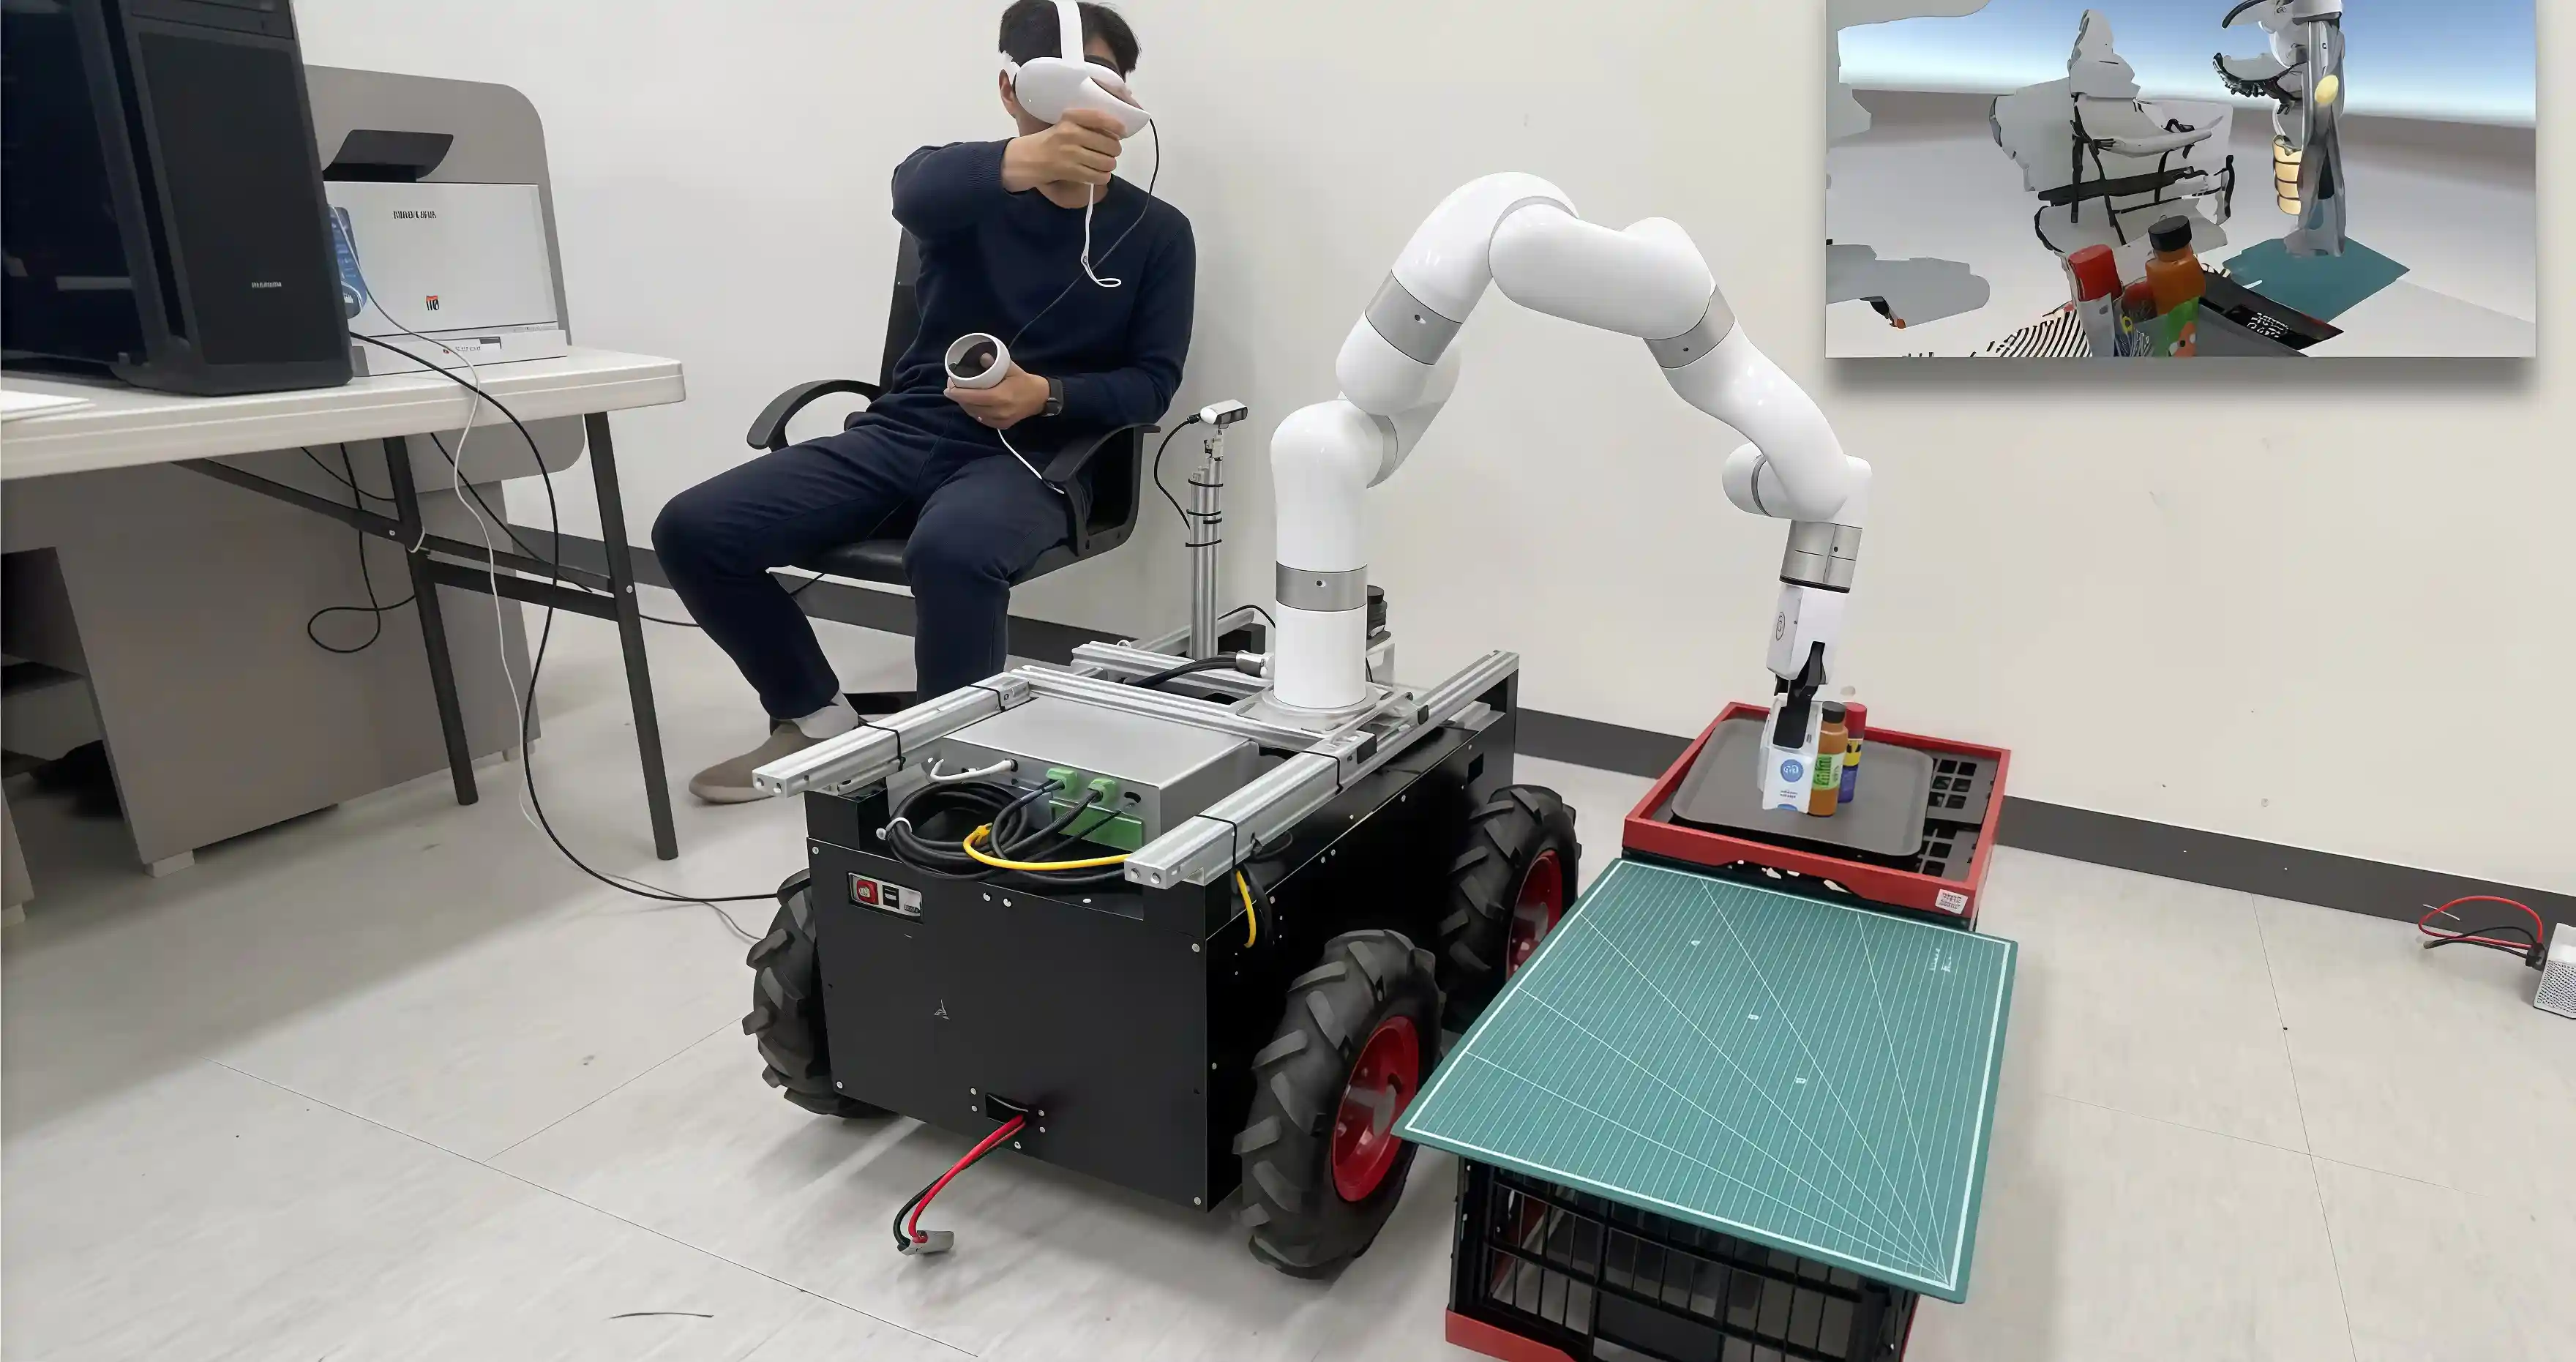
AMR Labs integrated the UFACTORY xArm into two distinct research and development applications: a VR teleoperation system that allows an operator to remotely control the xArm-equipped mobile robot from a first-person virtual perspective, and an autonomous bin picking system where the xArm identifies and picks objects from unstructured bins without human intervention. Together, these two modes—supervised teleoperation and full autonomy—form AMR Labs’ approach to flexible mobile manipulation.
Customer Profile

Company:
AMR Labs Inc.

Industry:
Industrial Automation

Region:
Korea

Robot Used:
UFACTORY xArm

Application:
VR Teleoperation, Autonomous Bin Picking
Key Benefits
ROS-native integration enables tight coupling with AMR navigation stack.
6-DOF reach supports both teleoperation dexterity and autonomous picking.
Lightweight design keeps mobile platform payload budget manageable.
Open SDK enables custom VR control interface development.
Research-grade performance at a price accessible to a seed-stage startup.
Tasks Solved
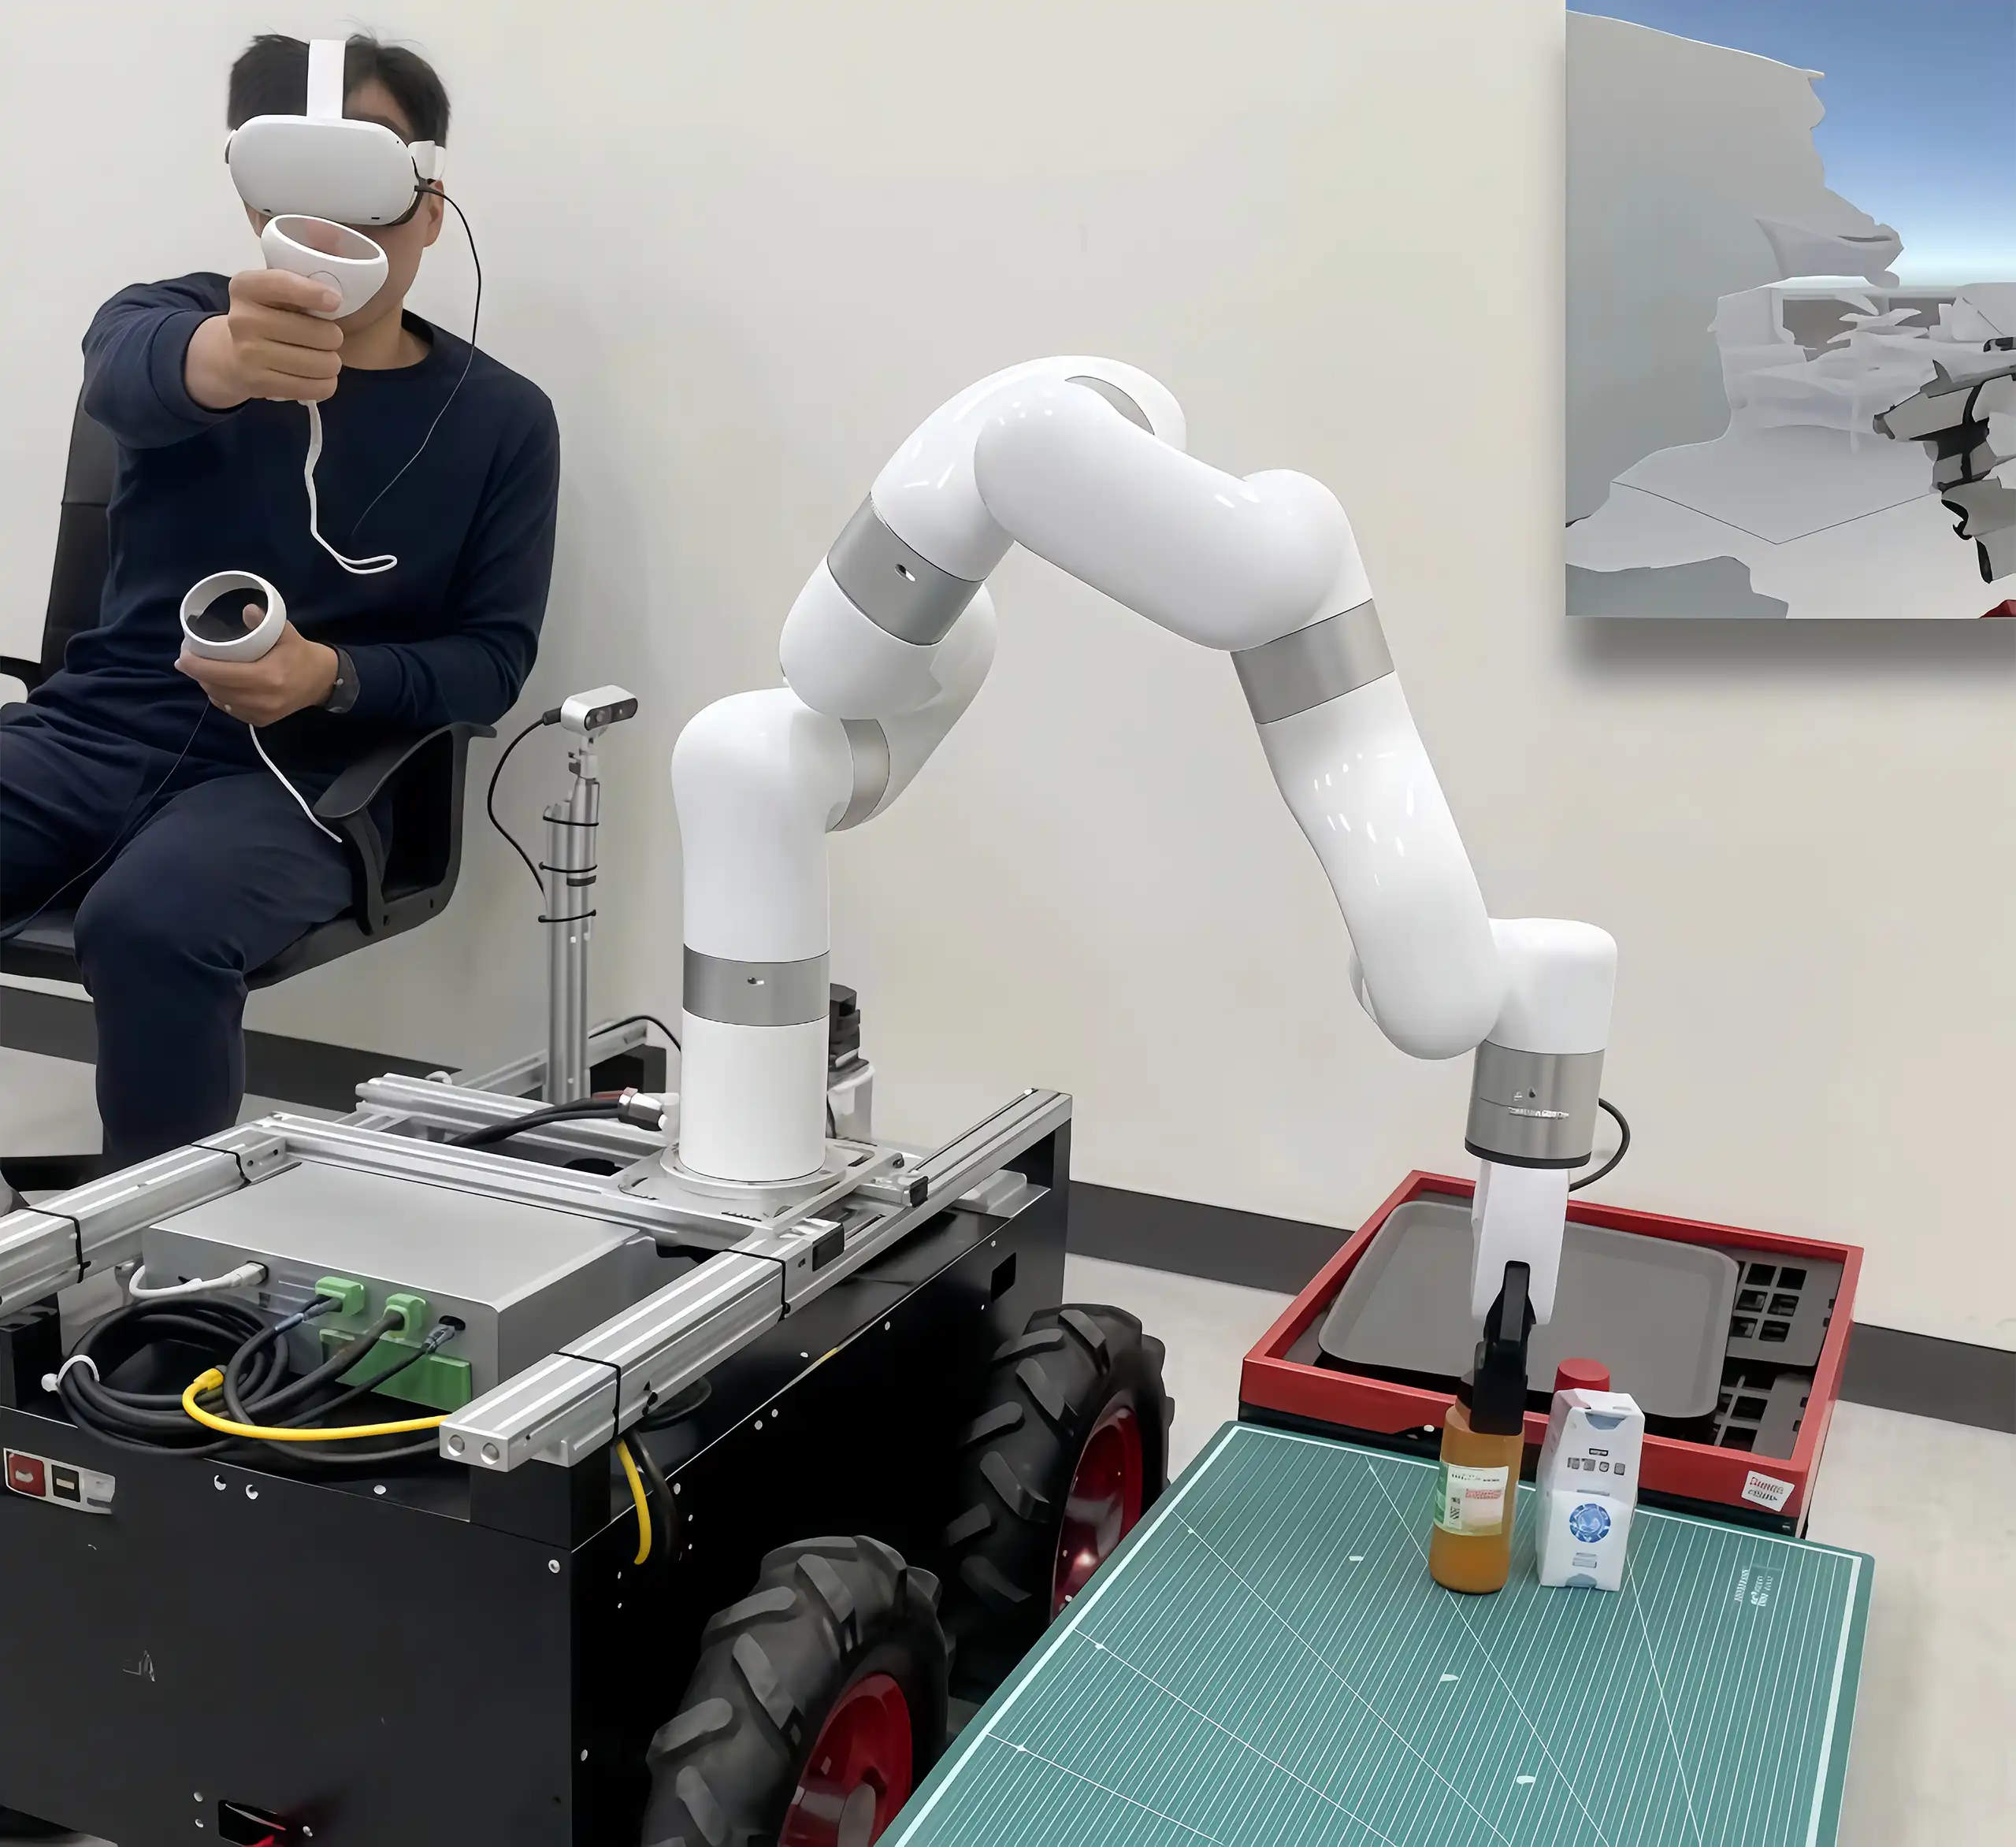
VR teleoperation of a mobile manipulator. An operator wearing a VR headset controls the xArm remotely from a real-time first-person perspective rendered in virtual space—enabling precise manipulation of objects at a distance, with full situational awareness through the robot’s onboard cameras.
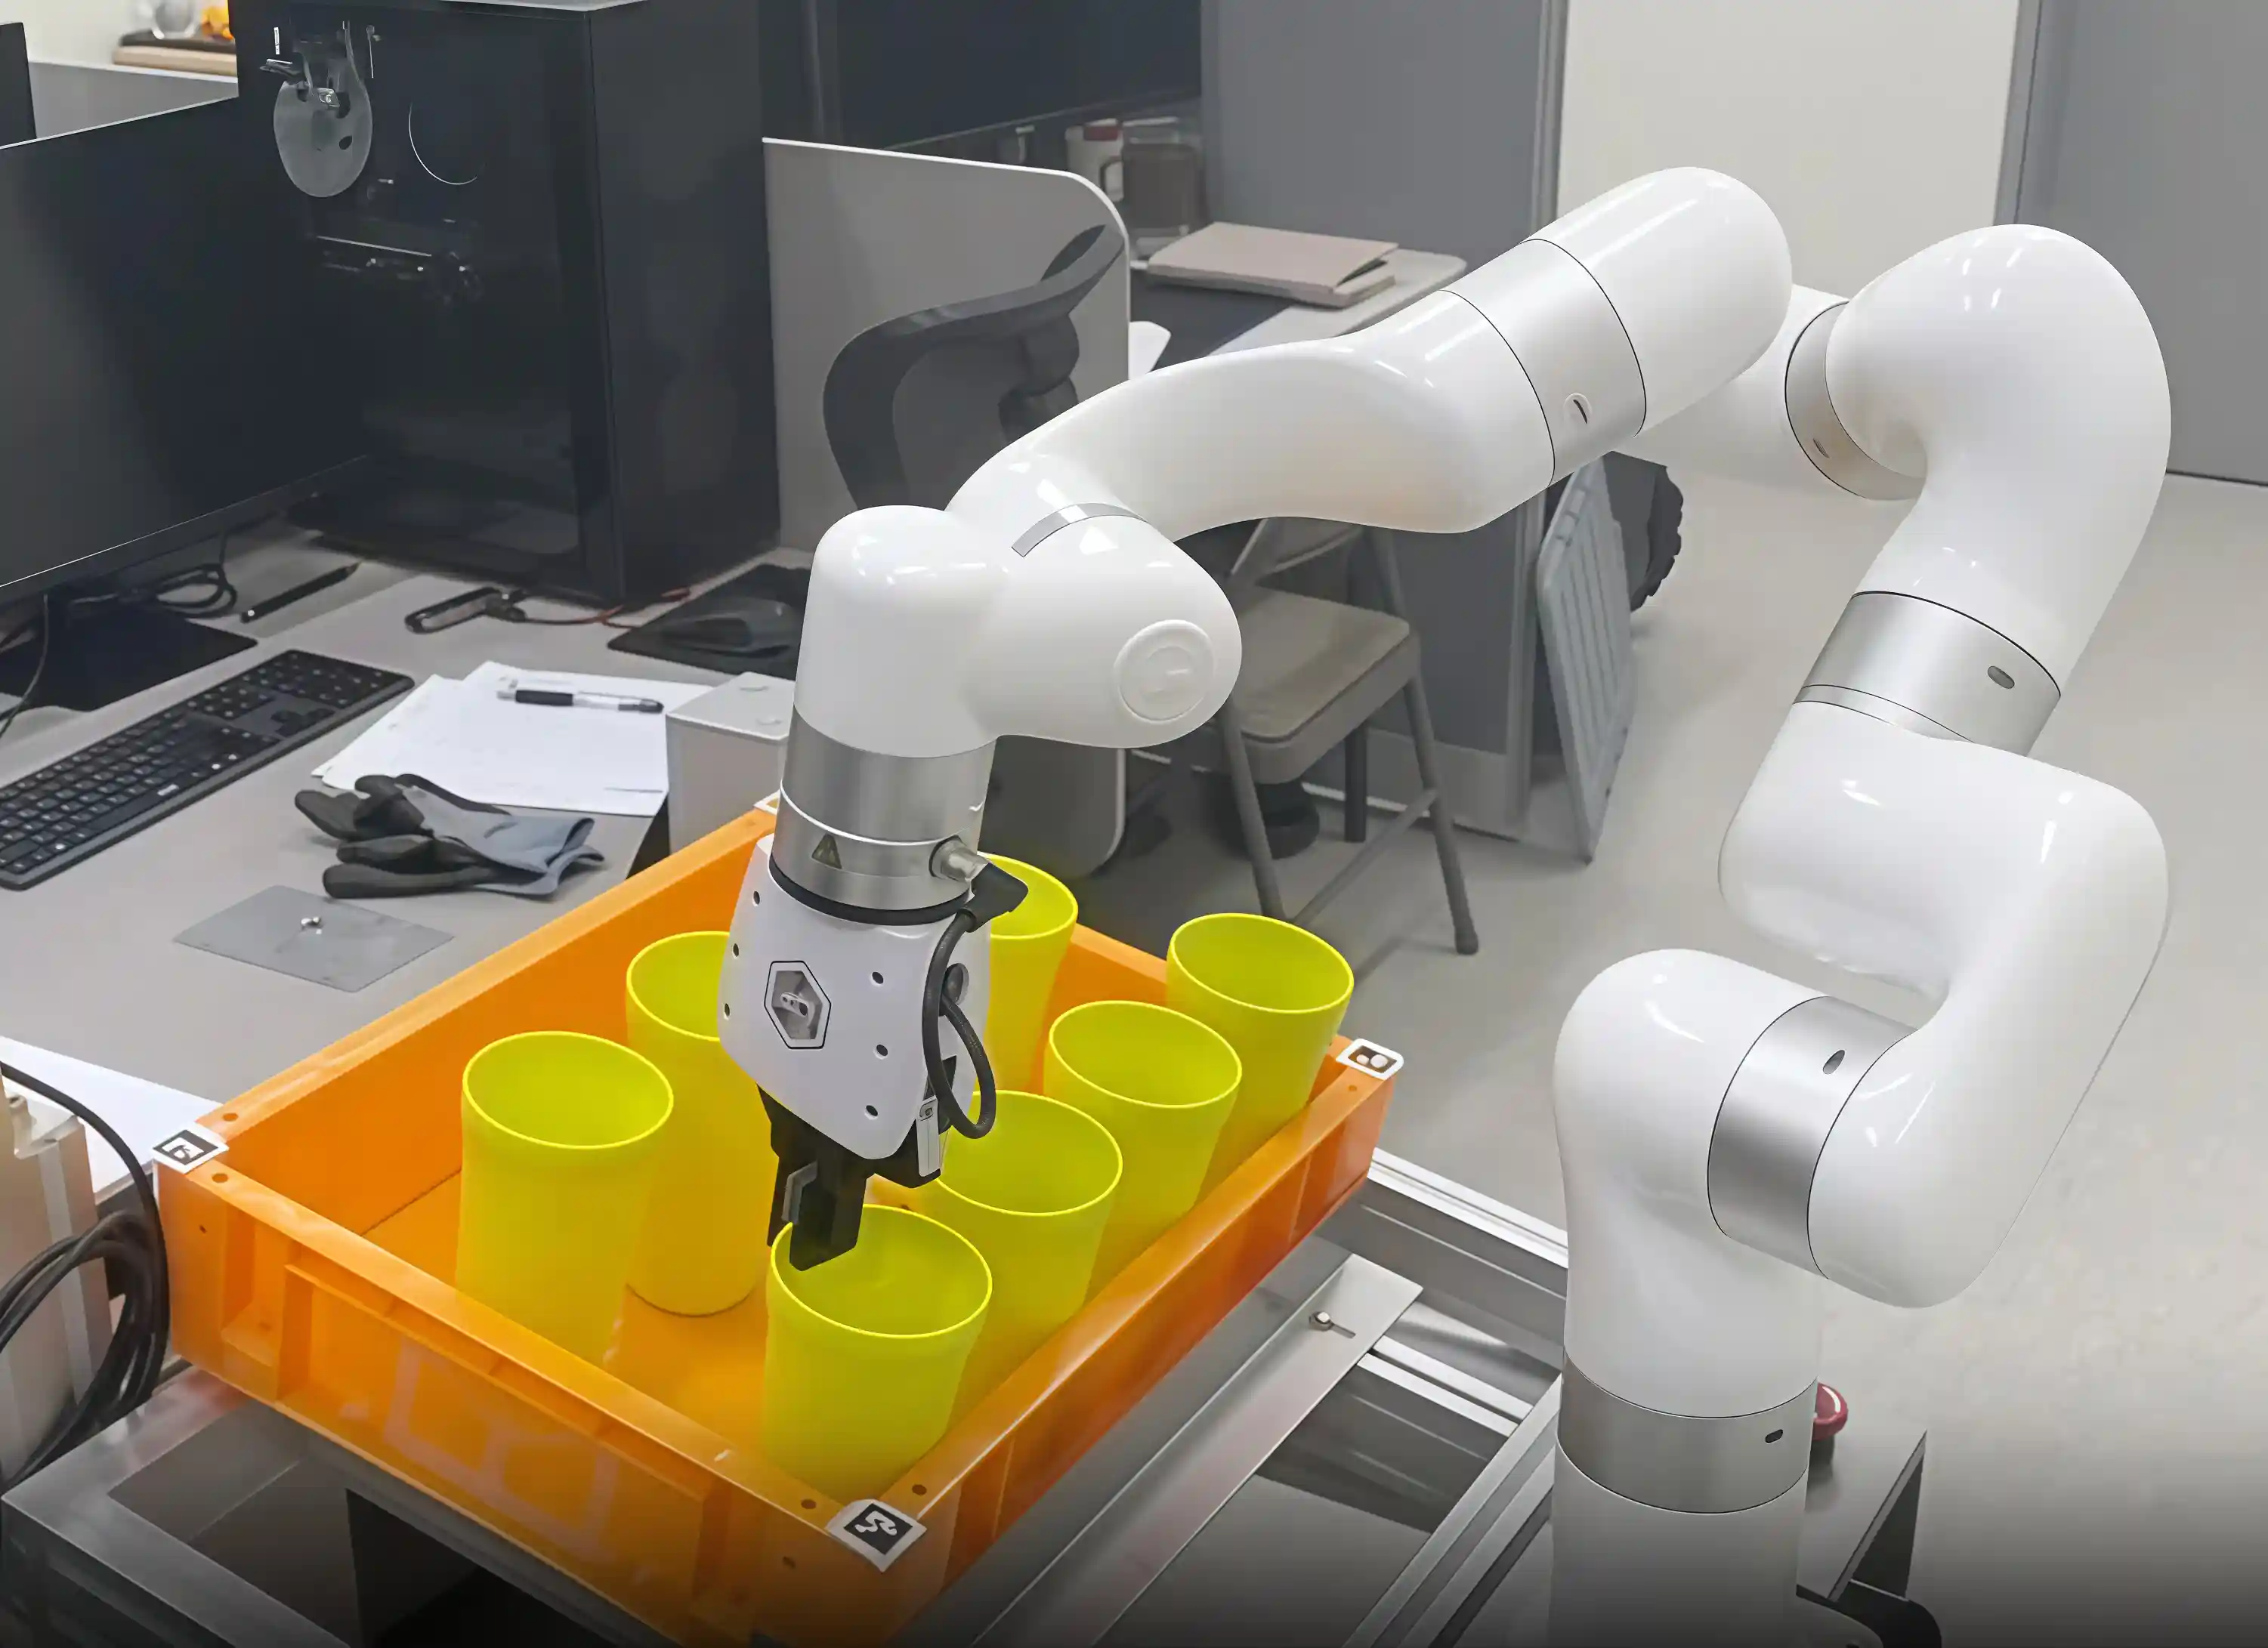
Autonomous bin picking. The xArm-equipped mobile robot autonomously detects and picks objects from unstructured bins using computer vision and motion planning—operating without continuous human supervision for repetitive logistics or warehouse picking tasks.
Benefits Achieved
Built a single hardware platform capable of both supervised teleoperation and fully autonomous operation—demonstrating two complementary modes of human-robot collaboration on one system.
Achieved seamless integration between the xArm and the AMR platform’s ROS-based navigation and perception stack, enabling coordinated whole-body motion between the mobile base and the arm.
Developed a VR teleoperation interface that translates intuitive hand controller input into precise robot arm motion—reducing the skill barrier for remote manipulation.
Demonstrated autonomous bin picking capability on an unstructured environment, a technically demanding application that validates the platform’s sensor integration and planning pipeline.
The Challenge
Two modes, one platform. Unpredictable tasks benefit from a human in the loop via VR teleoperation. Repetitive tasks like bin picking should run unattended once trained. AMR Labs needed hardware that could support both on a single system.
Startup constraints. The arm also had to fit an early-stage R&D budget, integrate cleanly into a ROS-based stack, and stay light enough not to burden the mobile platform—ruling out expensive or proprietary alternatives.
Why UFACTORY
The xArm matched AMR Labs’ technical requirements across every dimension that mattered for a mobile manipulator research platform.
ROS support, ready to integrate. AMR Labs’ entire platform runs on ROS—the navigation stack, the perception pipeline, and the task planner. The xArm’s official ROS package allowed the team to bring the arm into their existing software architecture without building custom middleware. That integration path directly shortened time from hardware arrival to first working demo.
6-DOF dexterity for both modes of operation. Teleoperation demands fluid, human-like motion across a wide workspace. Bin picking demands precise, repeatable approach trajectories. The xArm’s 6-DOF kinematics served both requirements—giving the operator full expressive control in VR mode and giving the autonomous planner the reach and articulation needed to work in unstructured bin environments.
Lightweight enough for a mobile platform. Every kilogram added to a mobile platform reduces battery life, maneuverability, and payload capacity. The xArm’s carbon fiber keeps arm weight low without sacrificing structural rigidity—an important constraint when the arm is mounted on a wheeled base rather than bolted to a factory floor.
Open SDK for custom VR control interface. The Python SDK gave them direct, low-latency access to the robot’s motion system—essential for a teleoperation application where control lag directly affects usability.
Startup-accessible pricing. Building a credible mobile manipulator demo requires a robot arm that a seed-funded team can actually purchase. The xArm’s price point made it possible for AMR Labs to equip their platform without exhausting their early-stage budget—allowing more resources to go toward the software, sensing, and integration work that differentiates their system.
Not sure which model fits your workflow?
Our team will match the right robot and configuration to your needs.