Teleoperation
Background
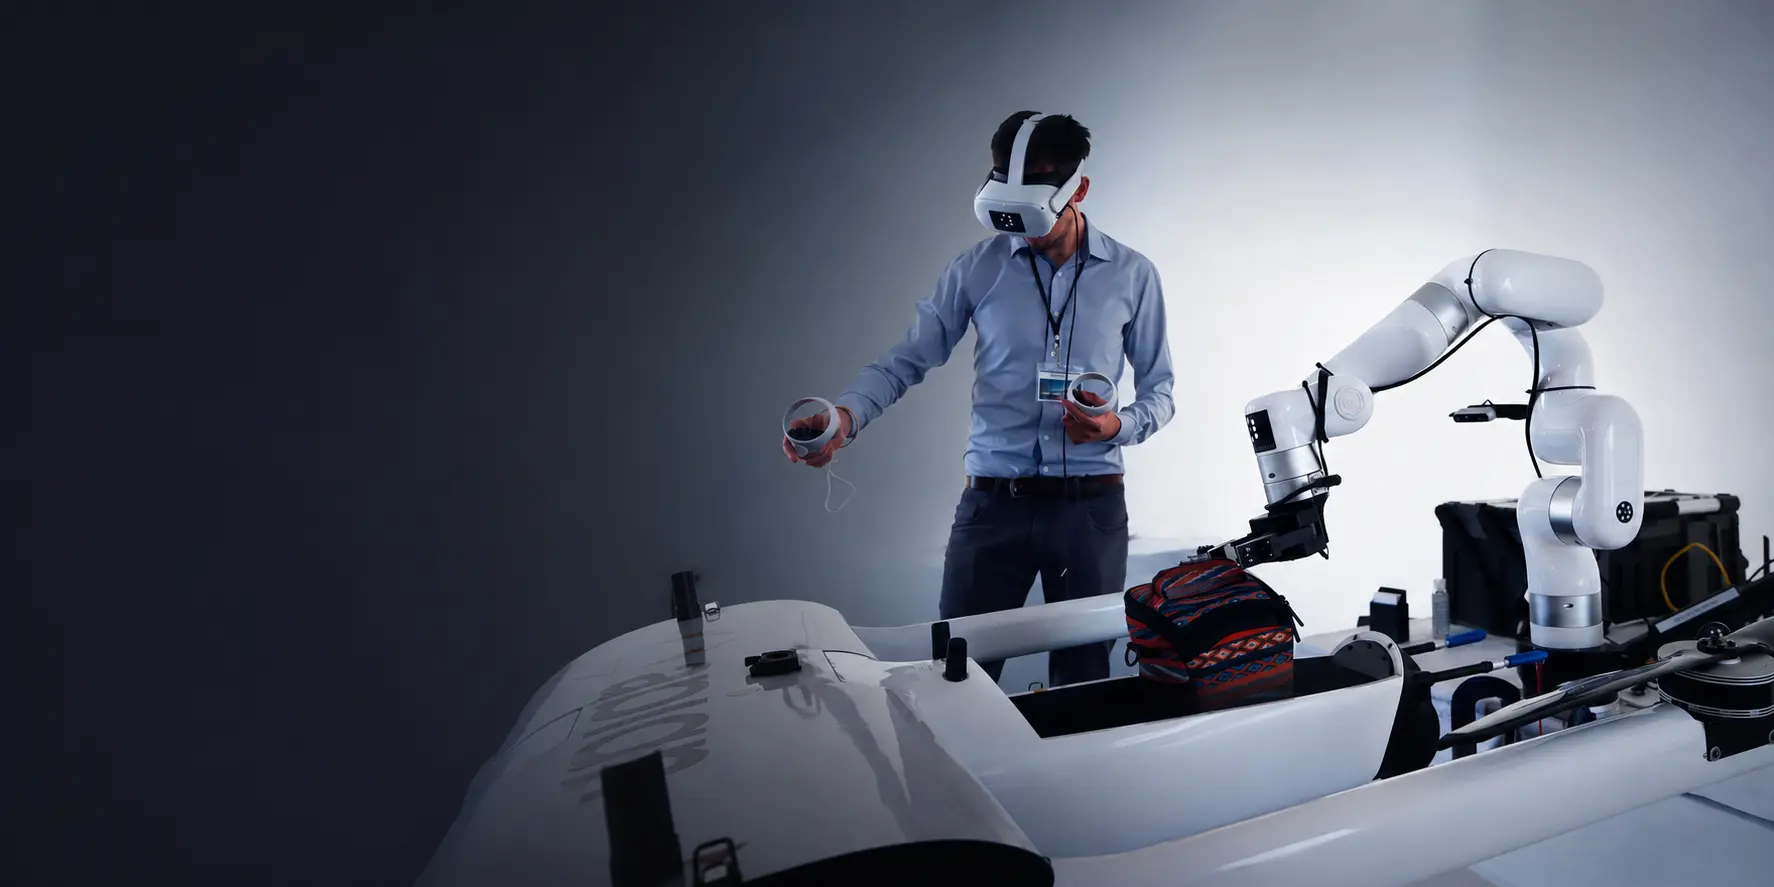
Teleoperation is gaining value in hazardous work, remote operations, and embodied AI data collection. Demand for teleoperated robot data to train AI is growing, which calls for robot platforms with open interfaces and low-latency response.
Barriers to Teleoperation

Hazardous Sites, Closed Systems, and Rigid Inputs
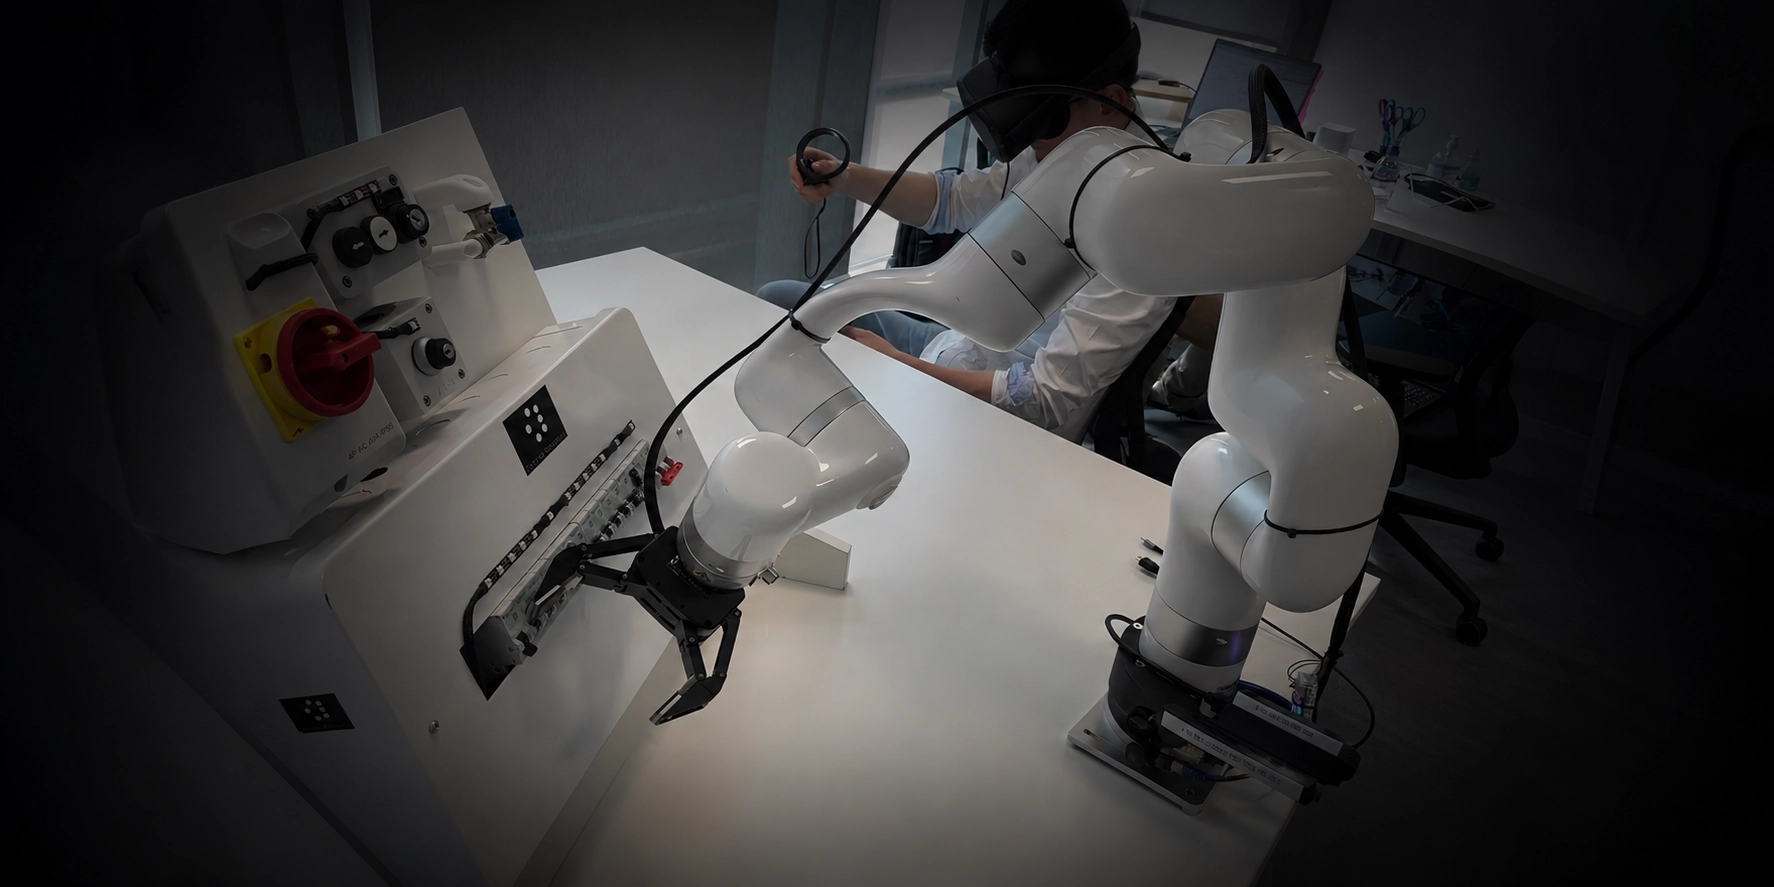
High-temperature, toxic, or radioactive environments require remote operation away from the site.
Quality teleoperation data collection needs an open, real-time robot platform.
Controllers, VR, motion capture, and other inputs need flexible integration.
 01
Open Development
ROS/ROS2 packages and Python/C++ SDKs help connect master arms, controllers, VR, motion capture, or another arm for custom teleoperation logic.
 02
Cost and ROI
As execution hardware or a data collection platform, UFACTORY cobots reduce hardware entry barriers for research institutions and integrators.
 03
Flexible Deployment
The lightweight carbon-fiber design and open interfaces support research, hazardous work, remote control, data collection, and other teleoperation scenarios.
 04
Precise Reproduction
Stable repeatability and motion control help reproduce operator trajectories and end-effector poses accurately at the robot side.
 05
Hazardous Reach
Remote operation lets users control the robot in high-temperature, toxic, radioactive, high-altitude, or hard-to-reach environments while keeping people safer.
 06
Data Collection Support
Open interfaces allow integrators and researchers to collect real task trajectories for imitation learning, robotics foundation models, and other AI training.
Related Case Studies
VR Teleoperation
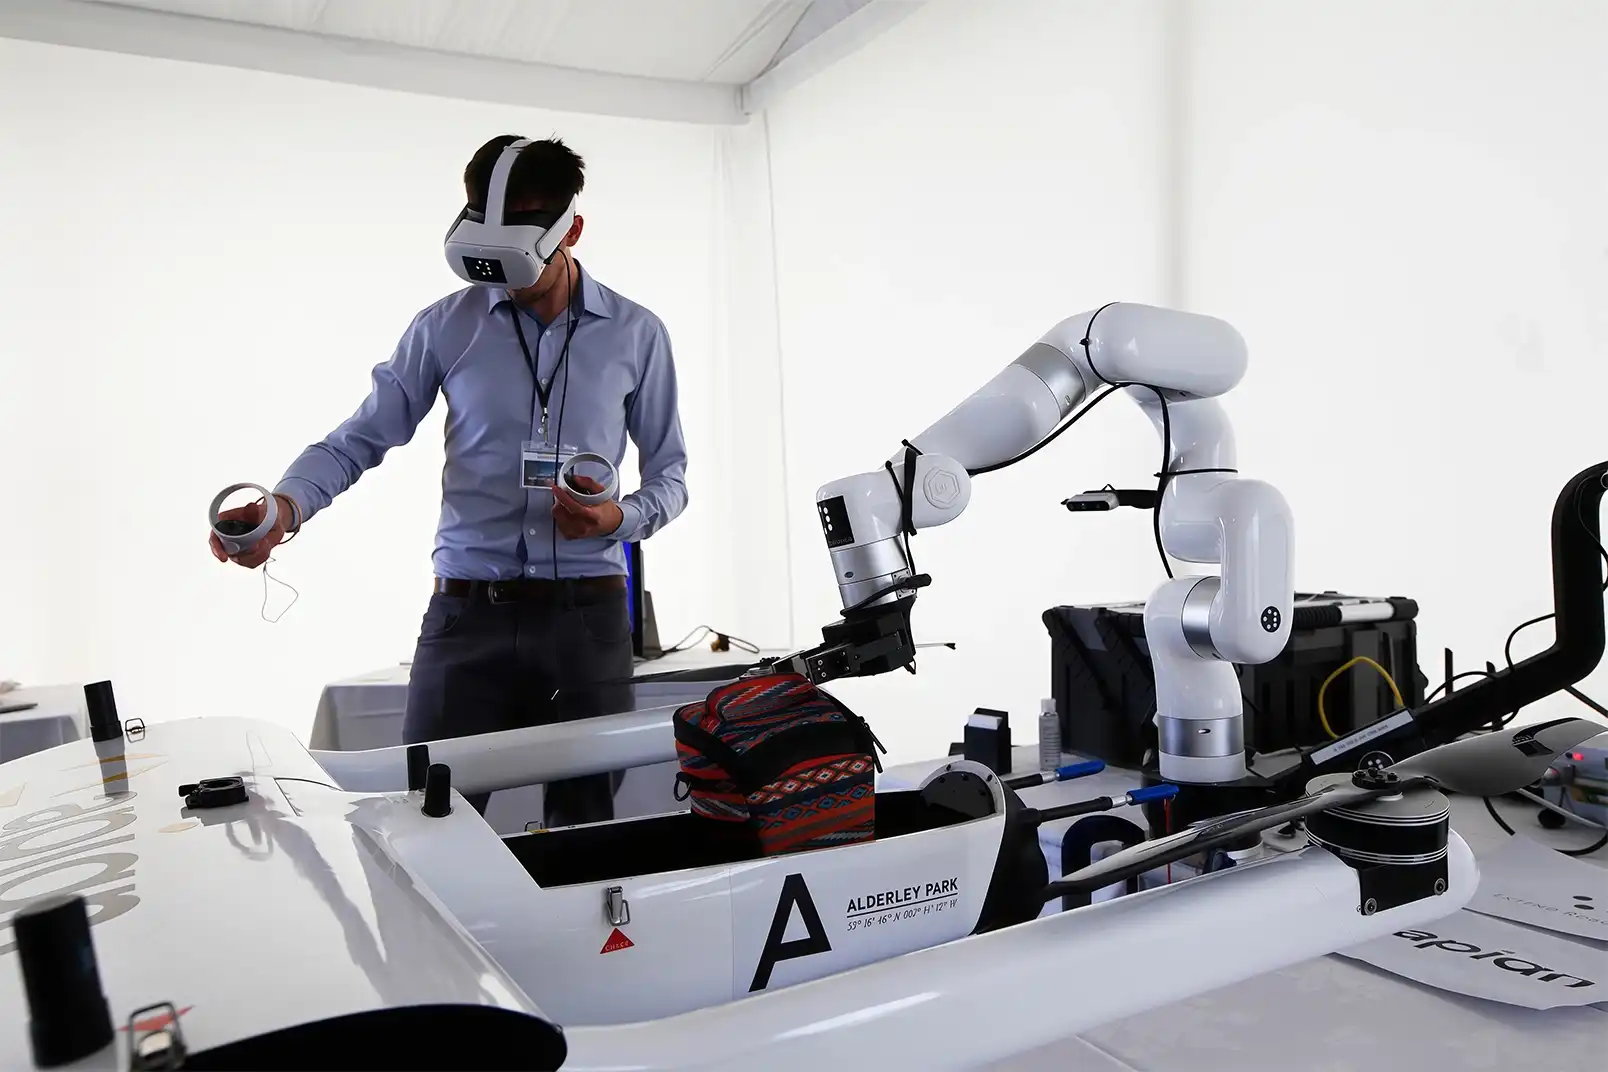
Extend Robotics
Accessible VR teleoperation using ROS-native xArm to solve labor shortages and safety risks in hazardous environments.
VR Teleoperation & Autonomous Bin Picking
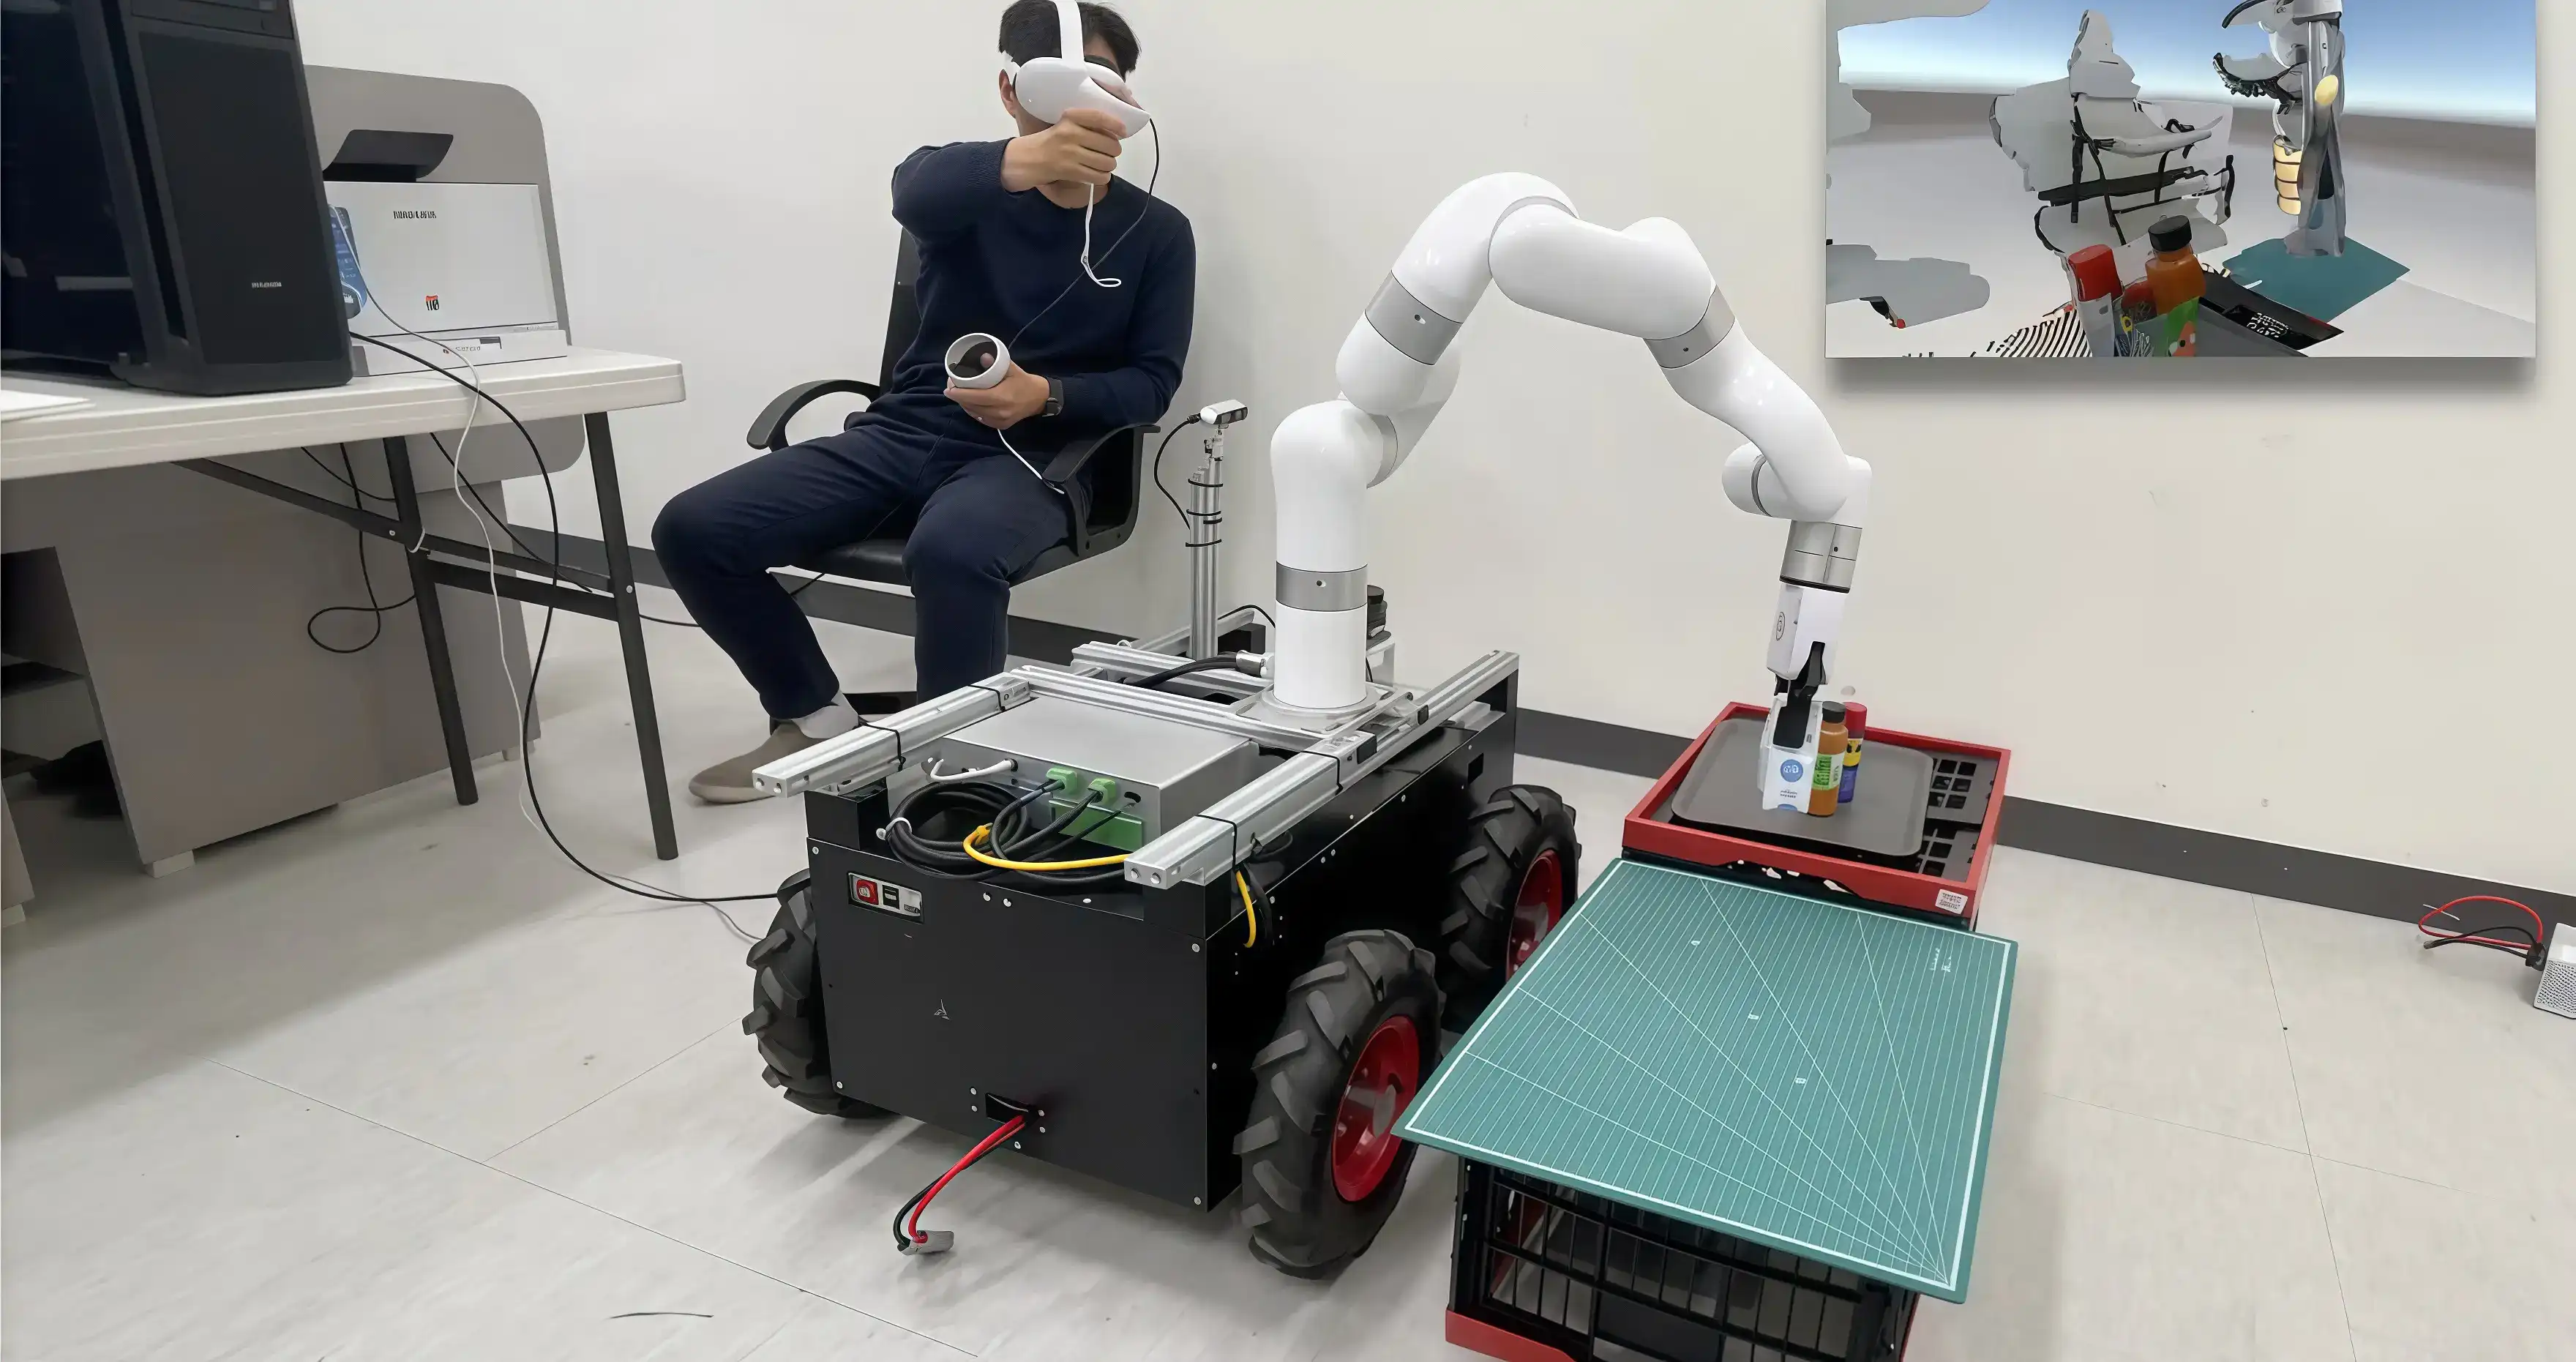
AMR Labs
AMR Labs developed VR teleoperation and autonomous bin picking applications with UFACTORY xArm.
Not sure which model fits your workflow?
Our team will match the right robot and configuration to your needs.