Agricultural Harvesting
Background
Agricultural labor shortages and workforce aging continue to intensify. Picking is one of the most labor-intensive and difficult-to-automate tasks, making fruit and vegetable picking robots a growing focus of research.
However, field environments are highly unstructured, and fruits are delicate and easily damaged. Overall, picking robots are still in the research and early commercialization stages. What researchers truly need is a flexible, open, and affordable platform for rapid validation of picking algorithms.
Barriers to Harvest Automation

Labour, Delicacy, and Changing Fields
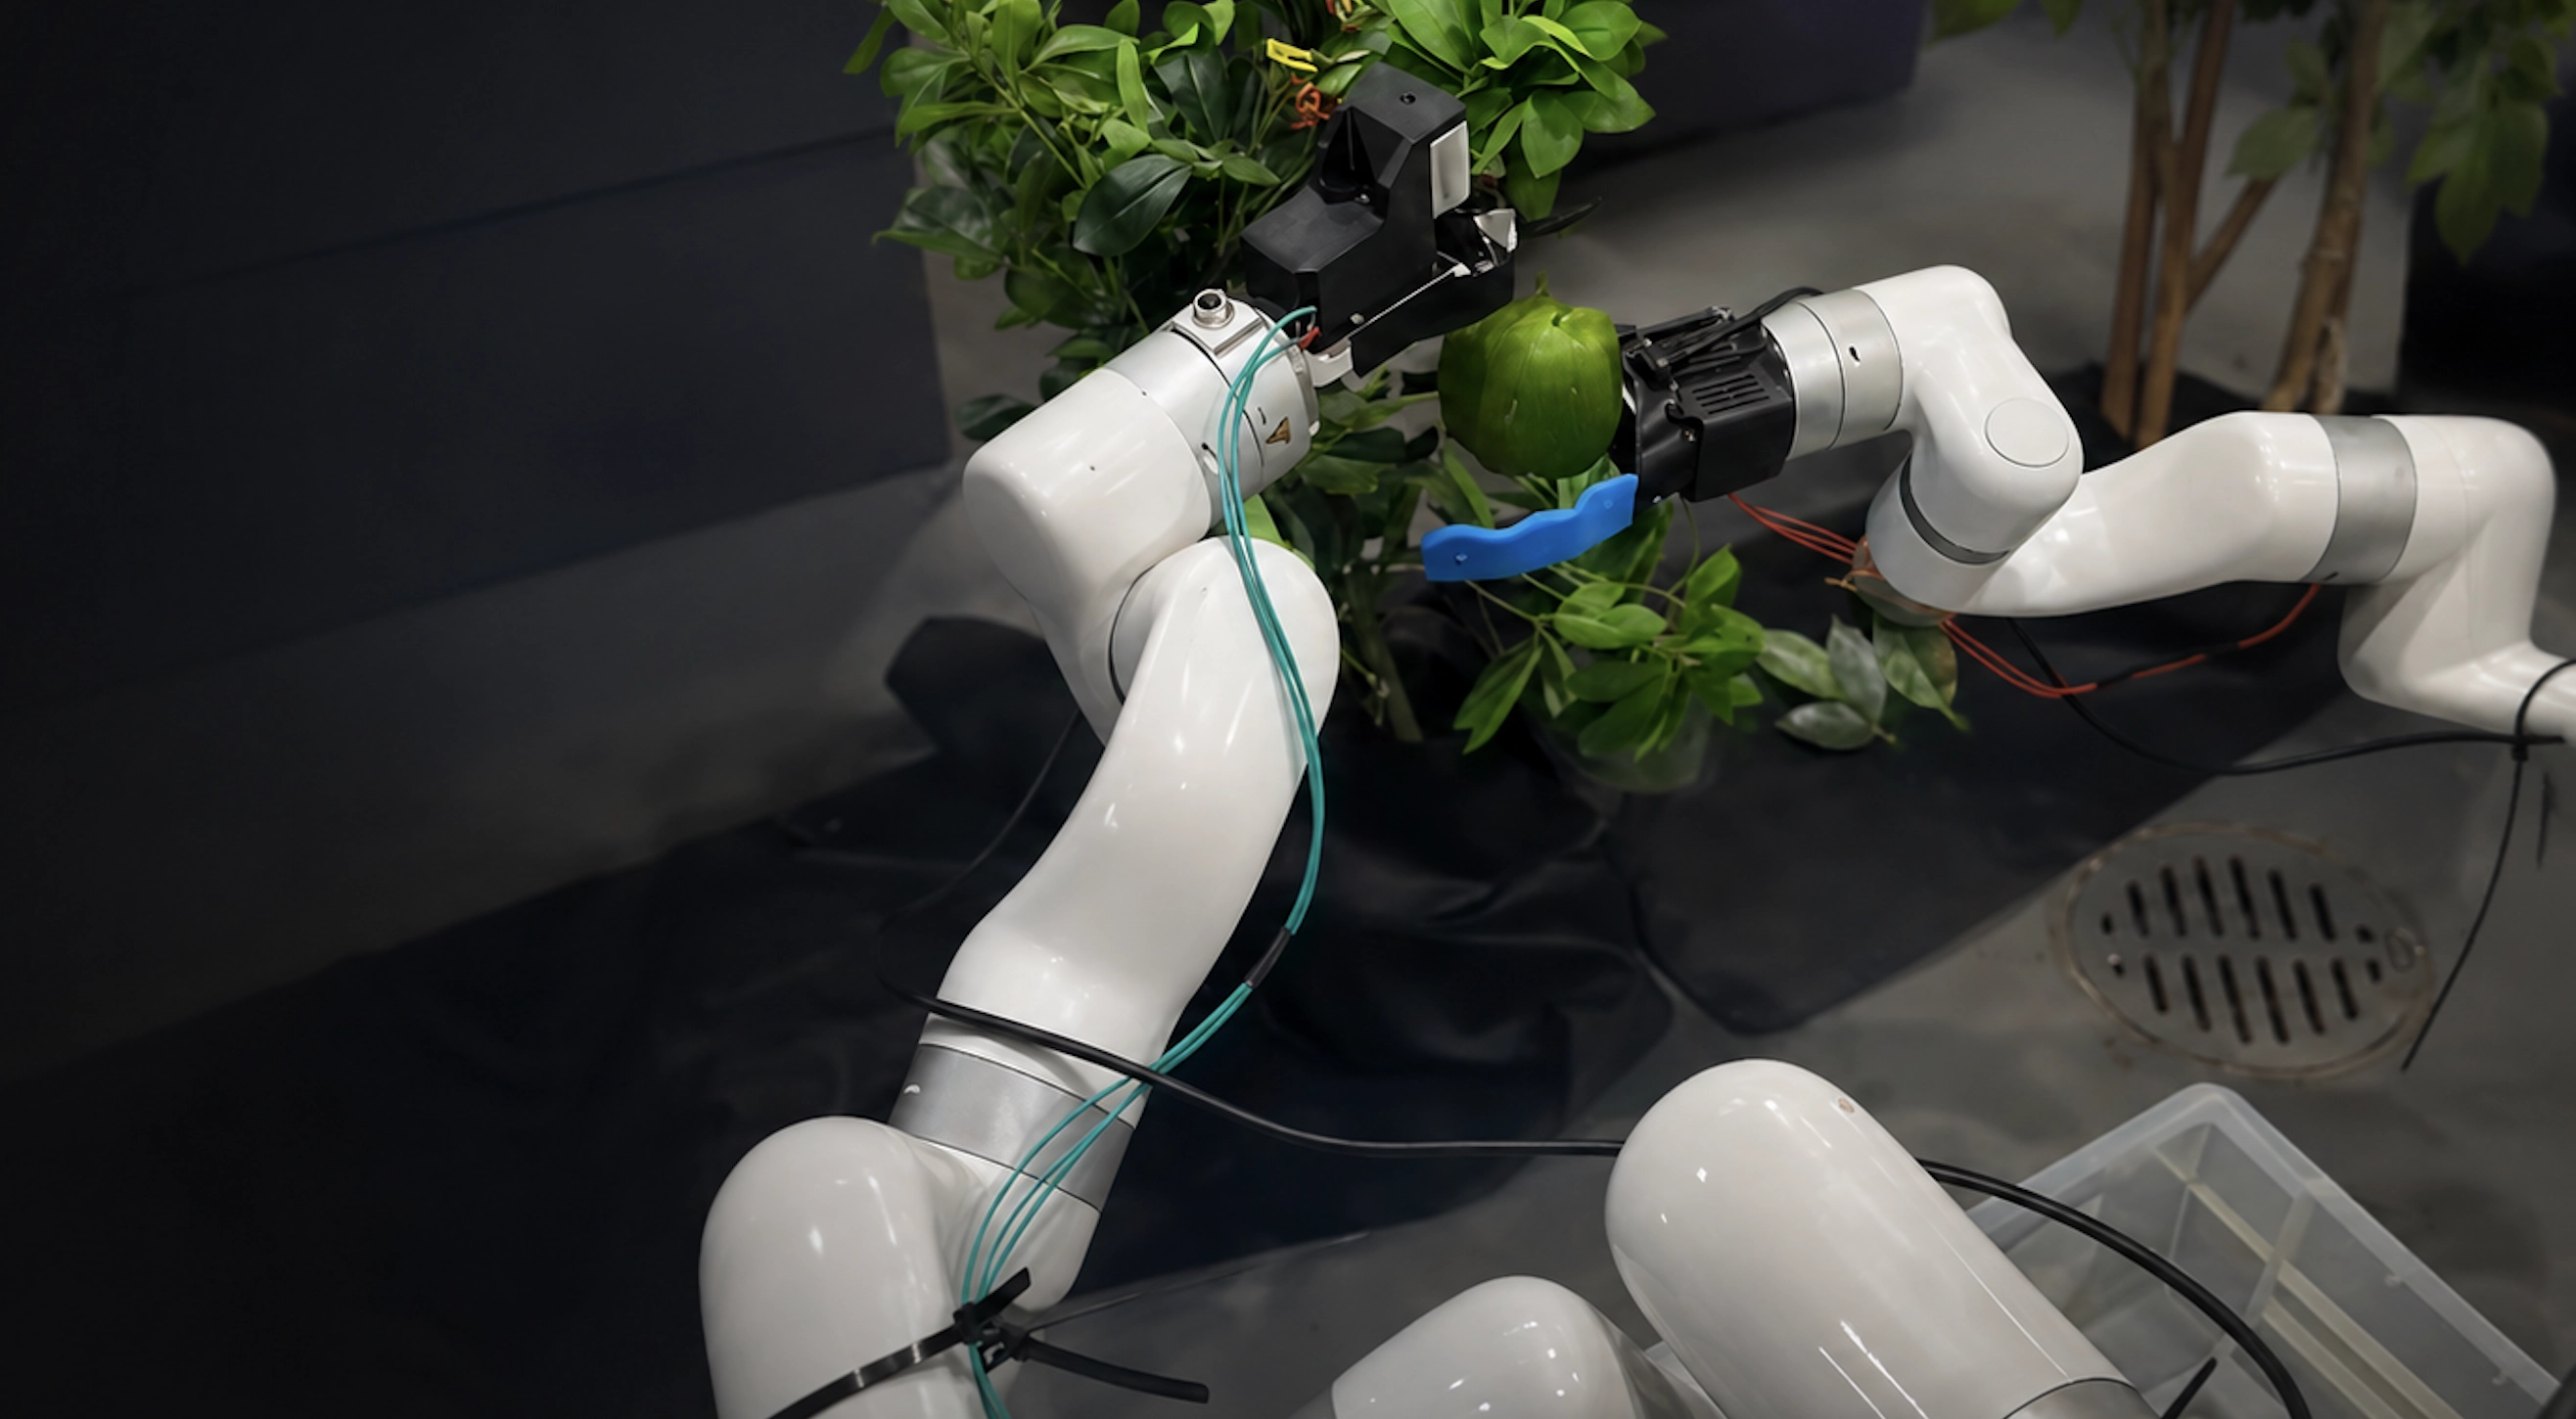
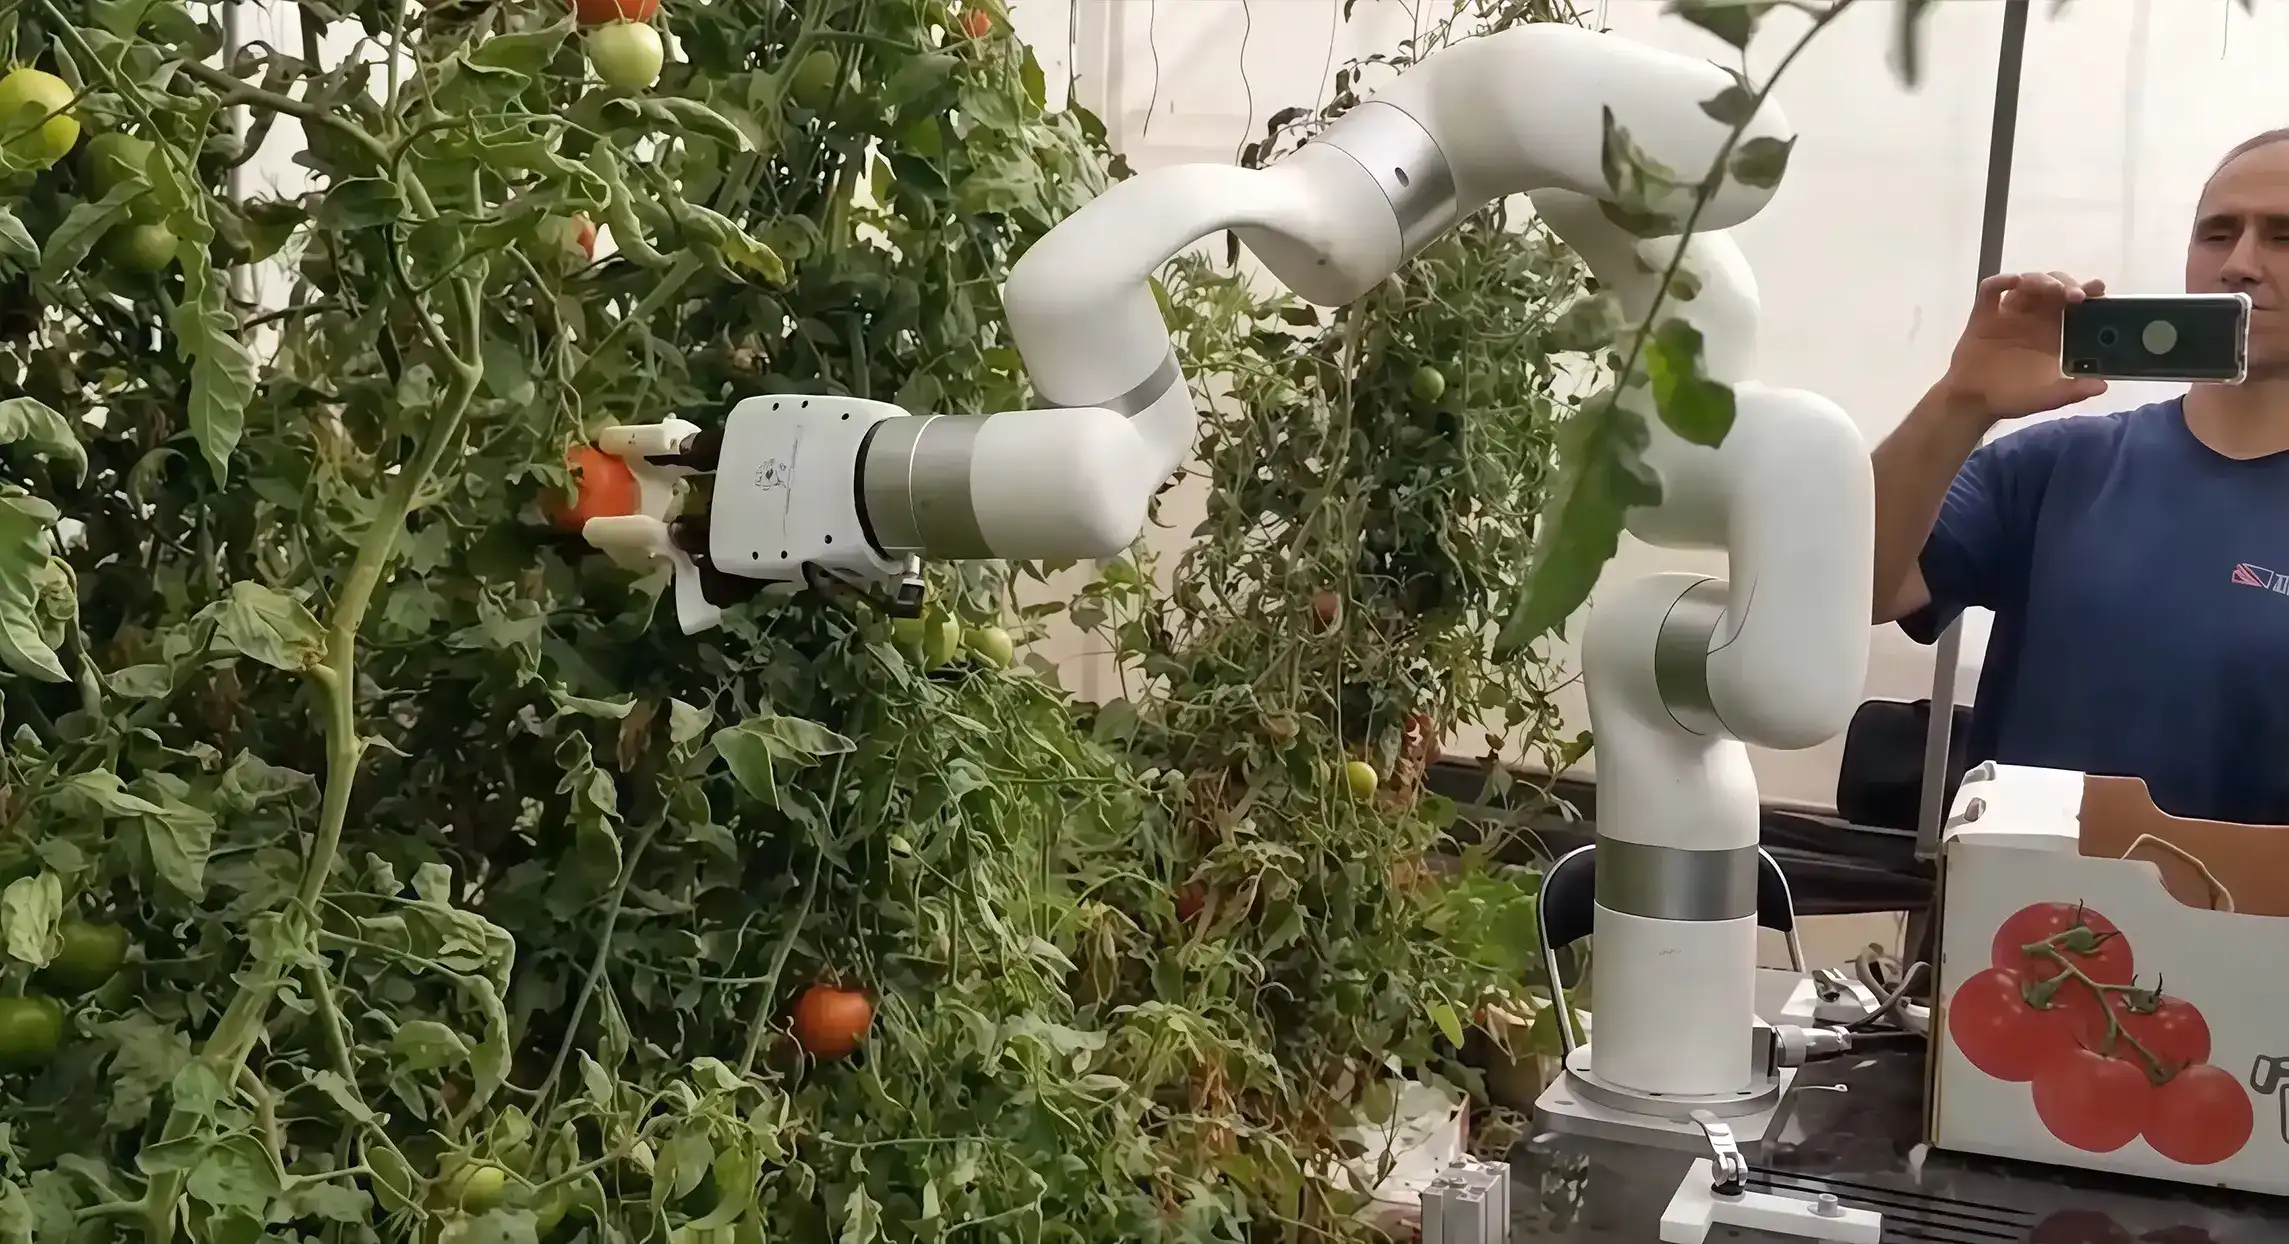
Harvesting remains difficult to automate because labour availability, crop maturity windows, and produce handling vary by season and field. Fruits and vegetables must be identified, localized, approached, and picked without bruising, while robots must adapt to occlusion, branches, leaves, and changing crop positions. Growers and researchers need open, flexible platforms to validate vision, grasping, and compliant picking strategies quickly and cost-effectively.
 01
Cost-Effective R&D
Competitive hardware costs help universities, agricultural research institutes, and startups validate picking robot concepts with lower R&D investment and faster iteration.
 02
Open Development Ecosystem
ROS/ROS2 packages and Python/C++ SDKs make it easier to connect vision, grasp planning, motion control, and crop-specific application logic.
 03
Vision-Ready Integration
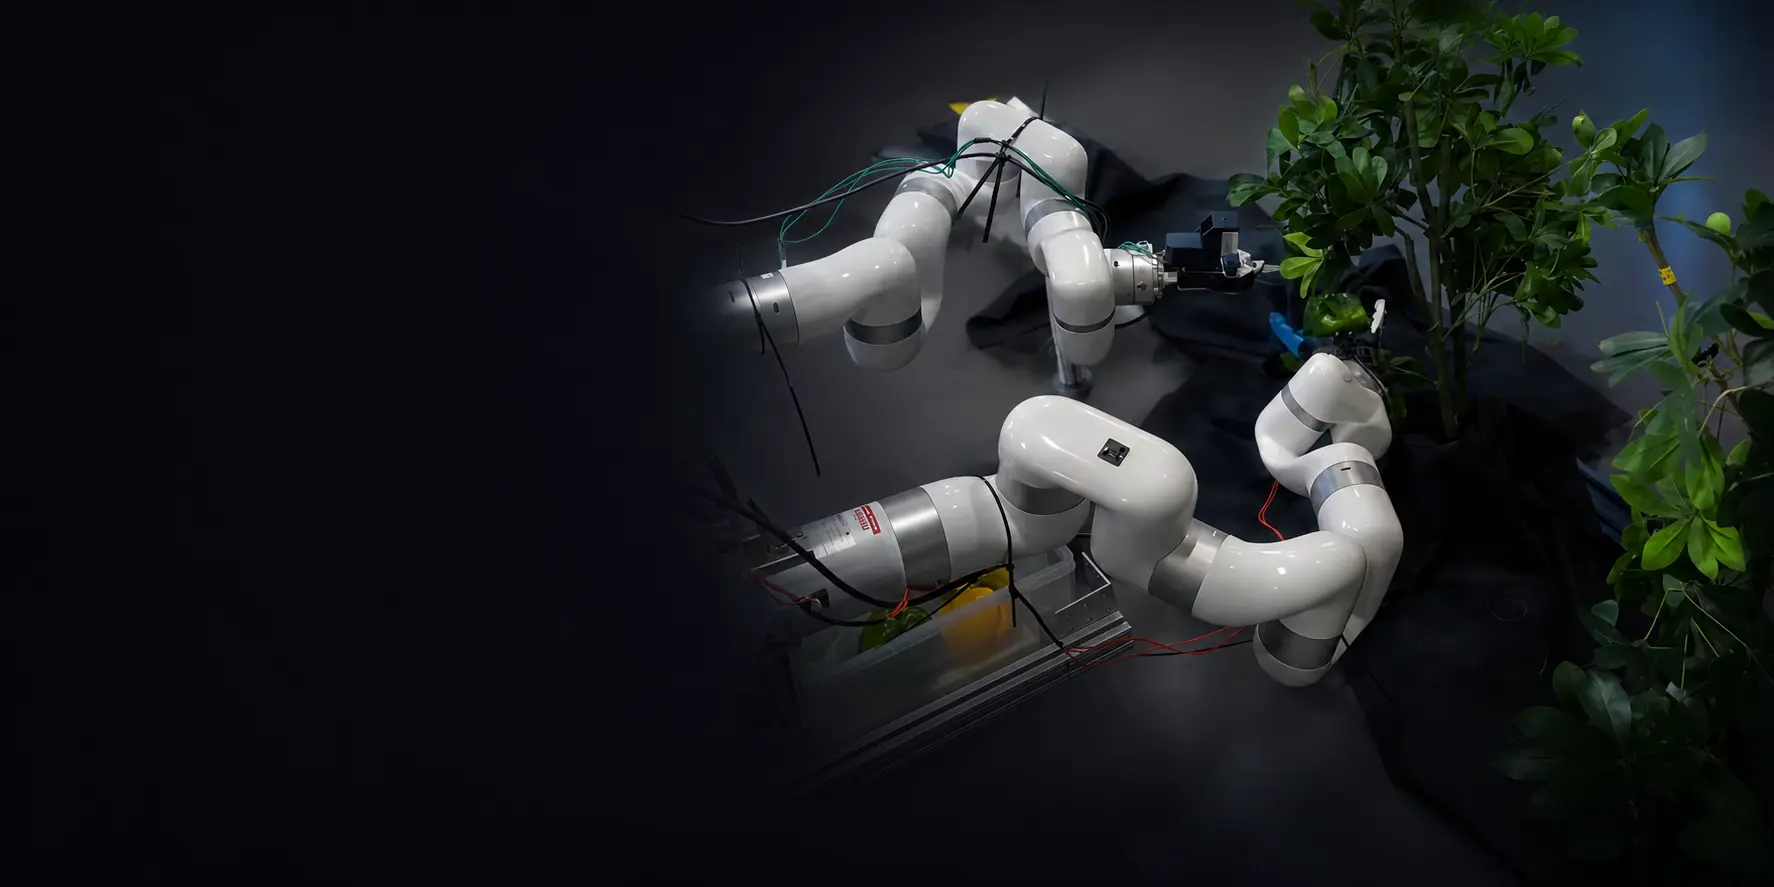
UFACTORY 850 supports built-in Gigabit Ethernet connectivity for 2D/3D cameras, enabling fruit recognition, ripeness assessment, 3D localization, and flexible vision solution development.
 04
Six-Axis Picking Flexibility
Six-axis motion lets the arm approach fruit from multiple angles, avoid branches and leaves, and adapt to changing fruit positions and orientations.
 05
Compliant Force Control
Optional six-axis force/torque sensing supports constant-force and compliant picking strategies, helping reduce bruising and protect delicate produce.
 06
Lightweight Mobile Deployment
Carbon-fiber construction makes the robot easy to move, redeploy, and integrate on mobile platforms for greenhouses, plastic tunnels, and field trials.
Not sure which model fits your workflow?
Our team will match the right robot and configuration to your needs.